

Catalog · How the catalog works
MuJoCo-Wrapper--Delphi-Demos

Delphi projects demonstrating real-time simulation and control via MuJoCo Wrapper
- ★ 5 on GitHub
Anyone may press Interesting, signed in or not. It helps others find this project.
README
MuJoCo-Wrapper Example Projects (Delphi)
Example projects demonstrating how to use the MuJoCo-Wrapper (Delphi)
for real-time physics simulation, humanoid control, and neural integration.
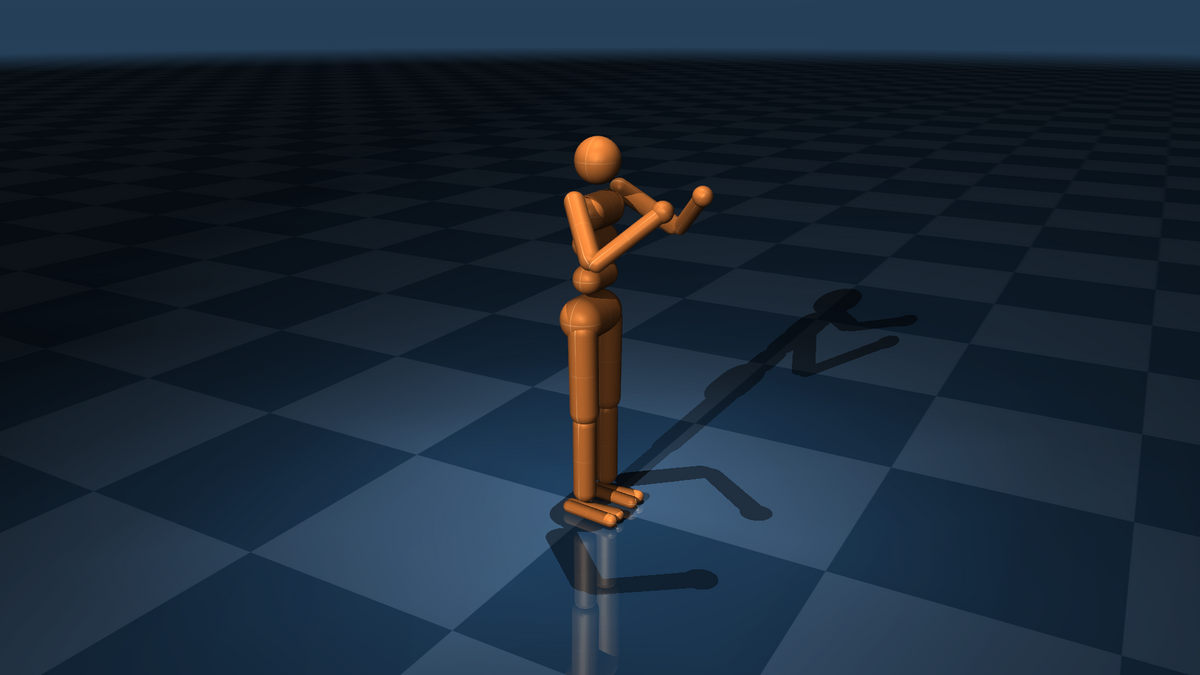
✨ Overview
This repository contains several Delphi / Object Pascal examples showcasing real-time integration with the MuJoCo physics engine through the custom C++ DLL wrapper (mujoco_delphi_wrapper.dll).
Each example demonstrates a different aspect of the wrapper API — from basic physics stepping and rendering, to multi-threaded humanoid control and live torque application.
🧩 Included examples
| Example | Description |
|---|---|
| Minimal Torso (Featherstone) | Simple body with one hinge joint and base motor control. |
| Two-Legs Creature | Bipod test model with alternating joint torques and balance simulation. |
| Humanoid Control | Full humanoid model with random torque input on hips, knees, and ankles. |
| Console Joint Logger | Non-visual example showing how to read qpos and qvel values in real time. |
All examples use:
- FMX-based rendering (OpenGL context)
- Native mouse camera (orbit / pan / zoom)
- The complete
MJW_*API from the MuJoCo-Wrapper (Delphi) DLL
🧠 Requirements
- MuJoCo-Wrapper (Delphi) — build this DLL first
- MuJoCo SDK installed or extracted
- Delphi 10.x or newer
- Windows 64-bit
mujoco_delphi_wrapper.dllin the same folder as the EXE
Optional (recommended):
- A GPU with OpenGL 3.3 or newer
- FMX multi-threading enabled for smoother rendering
🛠️ How to run the demos
- Build the wrapper
Follow the build guide from the main wrapper repository
to generatemujoco_delphi_wrapper.dll. - Open a demo project
In Delphi, open one of the example.dpror.lpifiles (e.g.MuJoCo_Test_Physics_V1.dpr). - Run
Make sure the DLL and the MuJoComodels\humanoid.xmlfile are in the working directory. - Interact
- Left mouse → Orbit camera
- Right mouse → Pan
- Scroll wheel → Zoom
- (Optional) Use
MJW_SetMouseCamParamsfor sensitivity tuning
📂 Repository structure
MuJoCo-Wrapper--Example-Code/
├─ examples/ │
├─ MuJoCo_Test_Physics_V1/ │
├─ Minimal_Torso/ │
├─ Two_Legs_Creature/ │
├─ Humanoid_Control/
│ └─ Console_JointLogger/ │
├─ examples_common/ │
├─ MujocoWrapper.pas │
├─ PhysicsThreadTemplate.pas
│ └─ FMXHelpers.pas │
├─ models/ │ └─ humanoid.xml │
├─ docs/ │ └─ demo_humanoid.png │
├─ README.md
└─ LICENSE.txt
🧭 Controls (FMX viewer)
| Action | Input |
|---|---|
| Rotate camera | Left mouse drag |
| Pan camera | Right mouse drag |
| Zoom | Mouse wheel |
| Pause / resume | F5 |
| Quit | Esc |
🧱 Building from source
You don’t need to rebuild the C++ DLL for these demos.
Just copy the latest mujoco_delphi_wrapper.dll next to your Delphi project output folder.
To build the DLL from scratch, refer to the MuJoCo-Wrapper (Delphi) instructions (CMake + Visual Studio).
📘 Example code snippet
procedure TForm1.OnTick(Sender: TObject);
begin
  MJW_ClearApplied(H);

  // Read current joint angle and velocity
  var angle := MJW_Joint1D_Angle(H, 'knee_left');
  var speed := MJW_Joint1D_Vel(H, 'knee_left');

  // Simple PD torque control
  var target := 0.3;
  var torque := (target - angle) * 400 - speed * 10;
  MJW_ApplyDof(H, KneeL_Dv, torque);

  MJW_Step(H);
  MJW_Render(H);
  MJW_PollEvents(H);
end;

---

???? License

All Delphi example code in this repository is released under the MIT License ?? 2025 Roelof Emmerink.
See LICENSE.txt for details.

This repository depends on the MuJoCo-Wrapper (Delphi) project and the MuJoCo SDK, both licensed separately.

---

???? Acknowledgements

MuJoCo ??? Multi-Joint dynamics with Contact

GLFW ??? OpenGL window and input handling

Google DeepMind for open-sourcing MuJoCo

Roelof Emmerink ??? author of the MuJoCo-Wrapper (Delphi)