

Portal:Hardware and Robotics: what changed
Revision 3 to 4. Removed lines have a minus sign; added lines have a plus sign.
| Old | New | Line | |
|---|---|---|---|
| 1 | - | ||
| 1 | + | < [[Help:Contents|Lookup]] < [Portals](</Category:Portals> "Category:Portals") < **Portal:Hardware and Robotics** | |
| 2 | 2 | ||
| 3 | - | ||
| 3 | + | Portal:Hardware and Robotics | |
| 4 | 4 | ||
| 5 | - | ||
| 5 | + | [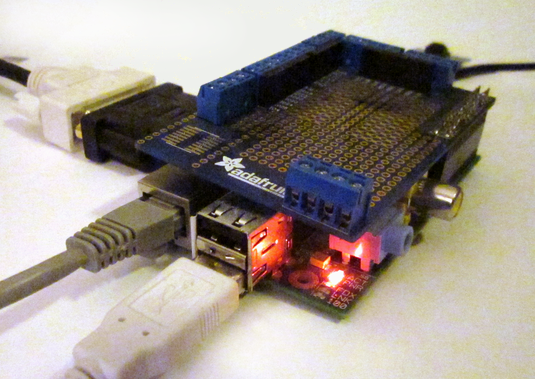](</File:rpi_with_adafruit_prototyping_plate.png>) · Applications of technical cybernetics include process control, feedback systems technology, measuring and instrumentation, embedded systems, automation, robotics, control of autonomous vehicles, avionics, internet of things and control of hardware components. Lazarus and Free Pascal have been successfully used in an increasing number of projects in this field of continuously growing importance. This portal summarizes articles on real world and demo implementations, algorithms and software projects that have been implemented with Lazarus and/or FPC. | |
| 6 | + | --- | |
| 7 | + | **Related topics** · **Platform Portals:** [[Portal:Android|Android]] \- [[Portal:Embedded|Embedded]] \- [[Portal:FreeBSD|FreeBSD]] \- [[Portal:iOS|iOS]] \- [[Portal:Linux|Linux]] \- [[Portal:Mac|Mac]] \- [[Portal:Windows|Windows]] · **Topic Portals:** [[Portal:New Users|**New Users**]] \- [[Portal:Databases|Database Development]] \- [[Portal:Game Development|Game Development]] \- Hardware and Robotics \- [[Portal:HowTo Demos|HowTo Demos]] \- [[Portal:SciTech|Science and Technology]] \- [[Portal:Web Development|Web Development]] · **Categories:** [Hardware](</Category:Hardware> "Category:Hardware") \- [Robotics](</Category:Robotics> "Category:Robotics") \- [Embedded](</Category:Embedded> "Category:Embedded") \- [FPC in Science and Technology](</Category:FPC_in_Science_and_Technology> "Category:FPC in Science and Technology") | |
| 8 | + | ||
| 9 | + | * [](</File:Zcad.png>) | |
| 6 | 10 | ||
| 7 | - | ||
| 11 | + | * [](</File:rpi_pinout_all_50.png>) | |
| 8 | 12 | ||
| 9 | - | ||
| 13 | + | * [](</File:rpi_gpio_pins.png>) | |
| 10 | 14 | ||
| 11 | - | ||
| 15 | + | * [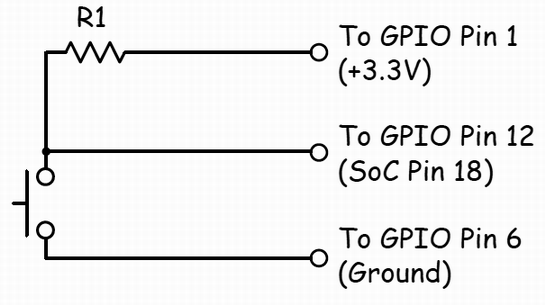](</File:rpi_testcircuit_2d.png>) | |
| 12 | 16 | ||
| 13 | - | ||
| 17 | + | * [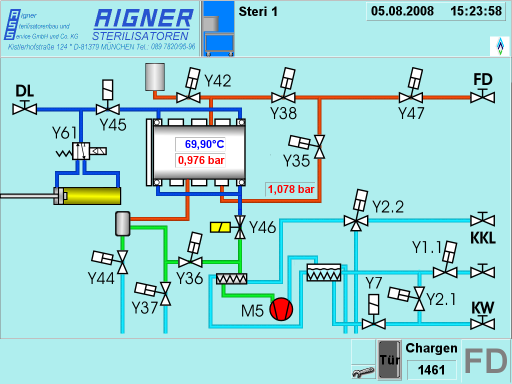](</File:StateDisplay.png>) | |
| 14 | 18 | ||
| 15 | - | ||
| 19 | + | Code Examples[[/wiki.freepascal.org/index.php?title=Template:Portal:Hardware and Robotics/Code Examples&action=edit|edit]] | |
| 16 | 20 | ||
| 17 | - | ||
| 21 | + | [[Hardware Access]] · [[TARGET Embedded]] · National instruments DAQ cards [[NIDAQmxExamples]] | |
| 22 | + | --- | |
| 23 | + | ||
| 24 | + | ||
| 18 | 25 | ||
| 26 | + | Embedded Systems[[/wiki.freepascal.org/index.php?title=Template:Portal:Hardware and Robotics/Embedded Systems&action=edit|edit]] | |
| 27 | + | ||
| 28 | + | [[TARGET Embedded|Overview of embedded systems]] \- without an operating system · [[Embedded|Overview of embedded systems]] \- with an operating system · [[ARM Linux Embedded Systems]] · [[i386 Linux Embedded Systems]] · [[AVR]] \- microcontrollers (eg ATMega or ATTiny) · [[FPC Embedded Nutshell]] · [[Lazarus on Raspberry Pi]] · [[TARGET Embedded Mipsel|MIPSel]] \- Microchip PIC32 microcontrollers · [[Odroid]] · [[Sanos]] · [[Ultibo core]] | |
| 29 | + | --- | |
| 30 | + | ||
| 31 | + | ||
| 32 | + | ||
| 33 | + | Packages, units and libraries[[/wiki.freepascal.org/index.php?title=Template:Portal:Hardware and Robotics/Libraries&action=edit|edit]] | |
| 34 | + | ||
| 35 | + | [[5dpo]] · [[Bluetooth]] · [[Lazarus on Raspberry Pi/de|PascalIO]] · [[PascalSCADA]] | |
| 36 | + | --- | |
| 37 | + | ||
| 38 | + | Special Topics[[/wiki.freepascal.org/index.php?title=Template:Portal:Hardware and Robotics/Special Topics&action=edit|edit]] | |
| 39 | + | ||
| 40 | + | [[Binutils]] · [[Control Pascal Tutorial]] · [[FPC Embedded Nutshell]] · [[maxint]] · Examples for [[NI-Scope examples|oscilloscopes]] by National Instruments · [[Native ARM Systems]] · [[Raspbian]] · [[Setup Cross Compile For ARM]] · [[Writing portable code regarding the processor architecture]] | |
| 41 | + | --- | |
| 42 | + | ||
| 43 | + | ||
| 44 | + | ||
| 45 | + | External Links[[/wiki.freepascal.org/index.php?title=Template:Portal:Hardware and Robotics/External Links&action=edit|edit]] | |
| 46 | + | ||
| 47 | + | [5dpo site](<http://paginas.fe.up.pt/~robosoc/en/doku.php>) · [Overview: Embedded and Industrial Control programs using Pascal](<http://controlpascal.com>) · [Short information on Lazarus and Raspberry Pi at eLinux.org](<http://www.elinux.org/Lazarus_on_RPi>) · [Getting Started with Pascal on the Pi](<http://www.pp4s.co.uk/main/gs-pi-intro.html>) · [Lazberry Pi: Comprehensive information on Lazarus on the Raspberry Pi computer](<http://superbitysoft.co.uk/lazberrypi/>). · [Real Time Scanning Probe Microscopy Interface](<https://github.com/chandranorth/RTSPM>) · [recording electrophysiological data](<http://www.mccauslandcenter.sc.edu/CRNL/tools/emg-recorder>) · [viewing electrophysiological data](<http://www.mccauslandcenter.sc.edu/CRNL/tools/elecro>) · [Main PascalSCADA site](<http://www.pascalscada.com>) · [PascalSCADA project at SourceForge](<http://sourceforge.net/projects/pascalscada/>) · [TurboControl: Embedded Free Pascal](<https://web.archive.org/web/20200610131345/http://www.turbocontrol.com:80/embeddedfreepascal.htm>) | |
| 19 | 48 | --- | |
| 20 | - | ||
| 21 | - | ||
| 22 | - | ||
| 23 | - | ||
| 24 | - | ||
| 25 | - | ||
| 26 | - | ||
| 49 | + | ||
| 50 | + | --- | |
| 51 | + | *From the Free Pascal wiki, page "Portal:Hardware and Robotics", as the Internet Archive kept it on 2025-06-16, last changed on 2020-03-10. Copyright stays with the author who wrote it, according to the old wiki's [[Licensing]] page. If you have concerns about this material, [message the admin](/wiki-contact).* |