

NumLib Documentation
Introduction
NumLib is a collection of routines for numerical mathematics. It was written by C.J.J.M. van Ginneken, W.J.P.M. Kortsmit, and L. Reij at the Technical University of Eindhoven (Netherlands) and donated to the Free Pascal project. Its beginnings date back to 1965. Originally written in Algol 60, ported to poorly formatted Pascal with strange procedure names, it is hard stuff, in particular because an official documentation is not readily available (well... -- Dutch documentation files in TeX can be found at http://www.stack.nl/~marcov/numlib/).
But after all, this library contains a series of very useful routines grouped into several units:
- Calculation of special functions (unit spe)
- Solution of systems of linear equations (unit sle)
- Finding roots of equations (unit roo)
- Fitting routines (unit ipf)
- Basic operations with matrices and vectors (unit omv)
- Matrix inversion (unit inv)
- Calculation of determinants (unit det)
- Calculation of eigenvalues (unit eig)
Therefore, it is the intention of this wiki article to create some useful documentation. Each routine described here was tested and its description will be accompanied by a working code example.
Note: This page heavily makes use of mathematical formulas written in LaTeX. In order to see these formulas in the browser JavaScript must be enabled.
Naming convention of routines
Would you imagine that a procedure named spears calculates the arcsin? The original NumLib routines limit the procedure/function names to 6 characters (maybe a limitation of Algol?). The first three characters always are identical with the name of the unit in which they are implemented. This leaves only three characters to differentiate between the routines...
Routines later added to the original library are given more conventional names, such as normaldist for calculation of the normal distribution.
Data types and declarations (unit typ)
Basic floating point type, ArbFloat
In NumLib, a new type ArbFloat is defined which is used as floating point type throughout the entire library. This allows to switch between IEEE Double (64bit) and Extended(80bit) (though big endian state is unknown at present).
At the time of this writing the $DEFINE ArbExtended is enabled, and therefore ArbFloat is identical to the standard type extended. In order to change the floating point type define or undefine ArbExtended and adapt the machineconstants to the type selected.
Basic integer type, ArbInt
Because in plain FPC mode the type Integer is 16-bits (for TP compatibility), and in Delphi 32-bits, all integers were changed to ArbInt. The basic idea is the same as with ArbFloat.
Vectors
NumLib often passes vectors to procedures as one ArbFloat plus some integer value. This ArbFloat value is the first value of an array containing the vector, the integer is the count of elements used from this array. Internally an array type is mapped over the first value in order to access the other array elements. This way both 0- and 1-based arrays as well as static and dynamic arrays can be passed to the functions and procedures of NumLib.
procedure DoSomething(var AVector: ArbFloat; n: Integer);
type
  TLocalVector = array[0..MaxElements] of ArbFloat;
var
  i: Integer;
  x: TLocalVector absolute AVector;
begin
  for i:=0 to n-1 do
    // do something with x[i]
end;

var
  x: array[1..100];   // Note: This array begins with index 1!
...
  DoSomething(x[1], 100);
Matrices
A matrix is a two-dimensional arrangement of numbers in m rows and n columns.
${A} = \left[ \begin{array}{cccc} a_{11} & a_{12} & a_{13} & \ldots & a_{1n}\\ a_{21} & a_{22} & a_{23} & \ldots & a_{2n}\\ \vdots & \vdots & \vdots & \ddots & \vdots\\ a_{m1} & a_{m2} & a_{m3} & \ldots & a_{mn} \end{array} \right]$
The matrix elements a<sub>ij</sub> are addressed by row and column indexes, i and j, respectively. In mathematics, the index values usually start with 1 (i = 1..m, j = 1..n) while in computing the first index is preferred to be 0 (i = 0...m-1, j = 0...n-1).
Generic matrices
In this type of matrix, no assumption is made on symmetry and shape of the data arrangement.
A constant (real) matrix can be declared in Pascal as a two-dimensional array of floating point numbers: A: array[1..m, 1..n] of ArbFloat (or A: array[0..m-1, 0..n-1] of ArbFloat in 0-based index notation). Similarly, a constant complex matrix can be declared as an array[1..m, 1..n] of complex.
When a NumLib procedure needs a matrix the first (top left) matrix element must be passed as a var parameter, along with the number of rows and columns. It is even possible to allocate larger arrays as needed, and in this case the allocated row length (or number of columns) must be specified.
Alternatively a matrix also can be specified as a one-dimensional array. This works because all data are found within the same memory block. The array index, k must be converted to the 2D matrix indexes, i, j:
  k := i * n + j      <==> i = k div n,           j := k mod n          {for 0-based array and matrix indexes}
  k := (i-1) * n + j  <==> i := (k-1) div n + 1,  j := (k-1) mod n + 1  {for 1-based array and matrix indexes}
Using a one-dimensional array is also the correct way to dynamically allocate memory for a matrix. The first idea of using an array of array of ArbFloat will not work because this does not allocate a single memory block. Instead, individual memory blocks will be allocated for the inner array (rows), and these pointers will be stored in the outer array - this way of storing 2D data is not compatible with the requirements of NumLib.
Here is a simple example how to create, populate and read a matrix dynamically
A = \left[
  \begin{array}{ccc}
  1 & 2 & 3 \\
  4 & 5 & 6
  \end{array}
\right]var
A: array of Arbfloat; // Note: the index in a dynamic array is 0-based.
ij: Integer;
i, j: Integer;
p: ^ArbFloat;
m, n: Integer;
begin
m := 2;
n := 3;
SetLength(A, m, n);
A[0] := 1; A[1] := 2; A[2] := 3;
A[3] := 4; A[4] := 5; A[5] := 6;
for i := 0 to m-1 do begin
for j := 0 to n-1 do begin
ij := i * n + j;
Write(A[ij]);
end;
WriteLn;
end;
// or
p := @A[0]; // pointer to first array element
for i:=0 to m - 1 do begin
for j := 0 to n - 1 do begin
WriteLn(p^);
inc(p); // advance pointer to next array element
end;
WriteLn;
end;Symmetric matrices
The elements of a symmetric matrix are mirrored at the main diagonal, i.e. a<sub>ij</sub> = a<sub>ji</sub>. In other words: a symmetric matrix is equal to its transpose: A = A<sup>T</sup>.
NumLib contains some routine optimized for such matrices. They require the matrix being stored like a generic matrix in a rectangular m x n array or a linear m*n array. However, only the half of the matrix below the diagonal must be populated (but it can be, of course).
Symmetric positive definite matrices
A matrix A is positive definite if the product d<sup>T</sup> A d is a positive number for any non-zero vector d. A matrix is symmetric positive definite if, additionally, A<sup>T</sup> = A.
This type of matrices has some interesting properties (determinant is never 0, eigenvalues are real and positive). Therefore NumLib offers specialized routines for many matrix problems with symmetric positive matrices which are superior to those for general matrices.
The matrix is stored in the conventional way like a rectangular 2D array of m rows and n columns or a linear 1D array with m**n* elements.
Band matrices
A n x n band matrix has zero elements everywhere except for a band along the main diagonal characterized by a left and right bandwidth (l and r, respectively).
The NumLib procedures for band matrices assume that the matrix stores only the elements of the band. It is expected the the matrix is passed as a 1D array. Starting at the top/left corner point of the matrix (element A<sub>11</sub>) the diagonal elements are collected by running along the rows of the matrix, from left to right and from top to bottom. In total, there will be n (l+1+r) - (r(r+1) + l(l+1)) div 2 elements. The calling procedure must allocate a 1D array of at least this size for the diagonal elements. Note that a band matrix cannot be passed as a 2D array.
As an example, suppose this 7 x 7 matrix with left bandwidth 2 and right bandwidth 1:
$A = \begin{bmatrix} A_{11} & A_{12} & 0 & 0 & 0 & 0 & 0 \\ A_{21} & A_{22} & A_{23} & 0 & 0 & 0 & 0 \\ A_{31} & A_{32} & A_{33} & A_{34} & 0 & 0 & 0 \\ 0 & A_{42} & A_{43} & A_{44} & A_{45} & 0 & 0 \\ 0 & 0 & A_{53} & A_{54} & A_{55} & A_{56} & 0 \\ 0 & 0 & 0 & A_{64} & A_{65} & A_{66} & A_{67} \\ 0 & 0 & 0 & 0 & A_{75} & A_{76} & A_{77} \end{bmatrix}$
The 1D data array to be passed to the NumLib routines consists of these elements
const
  arr: array[1..24] of ArbFloat = (
    A11, A22,
    A21, A22, A23,
    A31, A32, A33, A34,
         A42, A43, A44, A45,
              A53, A54, A55, A56,
                   A64, A65, A66, A67,
                        A75, A76, A77
  );
Symmetric band matrices
In a symmetric matrix, the matrix elements can be mirrored at the main diagonal of the matrix, i.e. A<sub>ij</sub> = A<sub>ji</sub>. All elements out side a band of width w to the left and right of the main diagonal are zero.
Like with a generic band matrix, NumLib assumes that the only the elements of the diagonals are passed as a 1D array to the procedures dedicated to this matrix type. Since in a symmetric band matrix the left and right band widths are equal it is assumed that only the left band and the main diagonal are stored. Again the relevant diagonal elements are collected by running across the rows of the matrix from left to right and from top to bottom, stopping in each row at the main diagonal. In total, there will be n (w+1) - w(w+1) div 2 elements in the data array.
As an example consider this 7 x 7 symmetric band matrix with band width 2:
$A = \begin{bmatrix} A_{11} & A_{21} & A_{31} & 0 & 0 & 0 & 0 \\ A_{21} & A_{22} & A_{32} & A_{42} & 0 & 0 & 0 \\ A_{31} & A_{32} & A_{33} & A_{43} & A_{53} & 0 & 0 \\ 0 & A_{42} & A_{43} & A_{44} & A_{54} & A_{64} & 0 \\ 0 & 0 & A_{53} & A_{54} & A_{55} & A_{65} & A_{75} \\ 0 & 0 & 0 & A_{64} & A_{65} & A_{66} & A_{76} \\ 0 & 0 & 0 & 0 & A_{75} & A_{76} & A_{77} \end{bmatrix}$
The 1D array for the NumLib procedures is
const
  arr: array[1..18] of ArbFloat = (
    A11,
    A21, A22,
    A31, A32, A33,
         A42, A43, A44,
              A53, A54, A55,
                   A64, A65, A66,
                        A75, A76, A77
  );
Tridiagonal matrices
A tridiagonal matrix has zero elements everywhere except for the main diagonal and the diagonal immediately above and below it. This way the matrix can be stored more efficiently than a generic matrix because all the empty elements can be dropped. The elements of an n x n square tridiagonal matrix can be stored as three vectors
- an array
lwithn-1elements for the subdiagonal - an array
dwithnelements for the main diagonal, and - an array
uwithn-1elements for the superdiagonal
$A= \begin{bmatrix} d[0] & u[0] & & \dots & 0 \\ l[1] & d[1] & u[1] & & \\ & l[2] & d[2] & u[2] & \\ \vdots & & \ddots & \ddots & \ddots \\ & & l[n-1] & d[n-1] & u[n-1] \\ 0 & & & l[n] & d[n] \end{bmatrix}$
Symmetric tridiagonal matrices
In these tridiagonal matrices, the subdiagonal and superdiagonal elements are equal. Consequently, NumLib requests only two, instead of three, one-dimensional arrays:
- an array
dwithnelements for the main diagonal, and - an array
cwithn-1elements for the superdiagonal and subdiagonal
$A= \begin{bmatrix} d[0] & c[1] & & \dots & 0 \\ c[1] & d[1] & c[2] & & \\ & c[2] & d[2] & c[3] & \\ \vdots & & \ddots & \ddots & \ddots \\ & & c[n-1] & d[n-1] & c[n] \\ 0 & & & c[n] & d[n] \end{bmatrix}$
Complex numbers
NumLib defines the type complex as a Turbo Pascal object. Real and imaginary parts are denoted as xreal and imag, respectively. Methods for basic operations are provided:
type
  complex  = object
    xreal, imag : ArbFloat;
    procedure Init(r, i: ArbFloat);    // Initializes the number with real and imaginary parts r and i, resp
    procedure Add(c: complex);         // Adds another complex number
    procedure Sub(c: complex);         // Subtracts a complex number
    function  Inp(z:complex):ArbFloat; // Calculates the inner product (a.Re * b.Re + a.Im * b.Im)
    procedure Conjugate;               // Conjugates the value (i.e. negates the imaginary part)
    procedure Scale(s: ArbFloat);      // Multiplies real and imaginary part by the real value s
    function  Norm: ArbFloat;          // Calculates the "norm", i.e. sqr(Re) + sqr(Im)
    function  Size: ArbFloat;          // Size = sqrt(Norm)
    function  Re: ArbFloat;            // Returns the real part of the complex number
    procedure Unary;                   // Negates real and imaginary parts
    function  Im: ArbFloat;            // Returns the imaginary part of the complex number
    function  Arg: ArbFloat;           // Calculates the phase phi of the complex number z = x + y i = r exp(i phi)
    procedure MinC(c: complex);        // Converts itself to the minimum of real and imaginary parts of itself and another value, c
    procedure MaxC(c: complex);        // Converts itself to the maximum of real and imaginary ports of itself and another value, c
    procedure TransF(var t: complex);
  end;
The real and imaginary parts of a complex number can also be retrieved by these stand-alone functions:
  function Re(c: complex): ArbFloat;
  function Im(c: complex): ArbFloat;
Basic operations with matrices and vectors (unit omv)
Inner product of two vectors
The result of the inner product of two vectors a = [a<sub>1</sub>, a<sub>2</sub>, ... a<sub>n</sub>] and b = [b<sub>1</sub>, b<sub>2</sub>, ... b<sub>n</sub>] (also called "dot product" or "scalar product") is a scalar, i.e. a single number. It is calculated as the sum of the element-by-element products of the vectors. Both vectors must have the same lengths.
$\mathbf{a} \cdot \mathbf{b} = \sum_{i=1}^n a_i b_i = a_1 b_1 + a_2 b_2 + \dots + a_n b_n$
NumLib provides the function omvinp for calculation of the inner product:
function omvinp(var a, b: ArbFloat; n: ArbInt): ArbFloat;aandbare the first elements of 1-dimensional arrays representing the vectors a and b, respectively.ndefines the dimension of the vectors (count of array elements). Both vectors must have the same number of elements.
Example
Calculate the dot product of the vectors a = [0, 1, 2, 2, -1] and b = [3, -1, -2, 2, -1].
program dot_product;

uses
  typ, omv;

const
  n = 5;
  a: array[0..n-1] of ArbFloat = (0, 1, 2, 2, -1);
  b: array[0..n-1] of Arbfloat = (3, -1, -2, 2, -1);

var
  ab: ArbFloat;
  i: Integer;

begin
  ab := omvinp(a[0], b[0], n);

  Write('Vector a = [');
  for i:= Low(a) to High(a) do
    Write(a[i]:5:0);
  WriteLn('  ]');

  Write('Vector b = [');
  for i:= Low(b) to High(b) do
    Write(b[i]:5:0);
  WriteLn('  ]');

  Write('Dot product a b = ');
  WriteLn(ab:0:0);
end.
Product of two matrices
The product of a m x n matrix A and a n x p matrix B is a m x p matrix C in which the elements are calculated as the inner product of the row vectors of A and the column vectors of B (see here for more details):
$C_{ij} = \sum_{k=0}^n A_{ik} B_{kj}$
The NumLib function to perform this multipication is omvmmm ("mmm" = multiply matrix by matrix):
procedure omvmmm(var a: ArbFloat; m, n, rwa: ArbInt;
                 var b: ArbFloat; p, rwb: ArbInt;
var c: ArbFloat; rwc: ArbInt);ais the first element of the first input matrix A. The array will not be changed.mspecifies the number of rows (or: column length) of matrix A.nspecifies the number or columns (or: row length) of matrix A.rwais the allocated row length of matrix A. This means that the array can be allocated larger than actually needed. Of course,rwacannot be smaller thann.
bis the first element of the second input matrix B. Again, this array will not be changed.pspecifies the number or columns (or: row length) of matrix B. The number of rows is already defined by the number of columns of matrix A,n.rwbis the allocated row length of matrix B.rwbcannot be smaller thanp.
cis the first element of the output matrix C. After the calculation, this and the following array elements will contain the elements of the product matrix.- The size of the output matrix is
mrows xpcolumns as set up by the input matrices A and B. rwcis the allocated row length of matrix C.rwccannot be smaller thanp.
- The size of the output matrix is
Example
Calculate the product of the matrices
$A = \begin{bmatrix} 3 & \ 5 & 4 & 1 & -4 \\ -2 & \ 3 & 4 & 1 & 0 \\ 0 & \ 1 & -1 & -2 & 5 \end{bmatrix} \ \ \ \ \ B = \begin{bmatrix} 3 & 4 & -2 & 0 \\ 0 & -2 & 2 & 1 \\ -1 & 0 & 3 & 4 \\ -2 & -3 & 0 & 1 \\ 1 & 3 & 0 & -1 \end{bmatrix}$
program matrix_multiplication;

uses
  typ, omv;

const
  m = 3;
  n = 5;
  p = 4;

  A: array[1..m, 1..n] of ArbFloat = (
    ( 3,  5,  4,  1, -4),
    (-2,  3,  4,  1,  0),
    ( 0,  1, -1, -2,  5)
  );
  B: array[1..n, 1..p] of ArbFloat = (
    ( 3,  4, -2,  0),
    ( 0, -2,  2,  1),
    (-1,  0,  3,  4),
    (-2, -3,  0,  1),
    ( 1,  3,  0, -1)
  );

var
  C: array[1..m, 1..p] of ArbFloat;
  i, j: Integer;

begin
  // Calculate product
  omvmmm(
    A[1,1], m, n, n,
    B[1,1], p, p,
    C[1,1], p
  );

  // Print A
  WriteLn('A = ');
  for i:= 1 to m do begin
    for j := 1 to n do
      Write(A[i, j]:10:0);
    WriteLn;
  end;
  WriteLn;

  // Print B
  WriteLn('B = ');
  for i:= 1 to n do begin
    for j := 1 to p do
      Write(B[i, j]:10:0);
    WriteLn;
  end;
  WriteLn;

  // Print C
  WriteLn('C = A B = ');
  for i:= 1 to m do begin
    for j := 1 to p do
      Write(C[i, j]:10:0);
    WriteLn;
  end;
end.
Product of a matrix with a vector
A matrix A of size m x n multiplied with a vector b of length n yields another vector of length m. The elements of the result vector c are the dot products of the matrix rows with b. Note that the length of vector b must be equal to the number of columns of matrix A.
$`\begin{align*} \mathbf{c} = A\ \mathbf{b}= \left[ \begin{array}{cccc} a_{11} & a_{12} & a_{13} & \ldots & a_{1n}\ a_{21} & a_{22} & a_{23} & \ldots & a_{2n}\ \vdots & \vdots & \vdots & \ddots & \vdots\ a_{m1} & a_{m2} & a_{m3} & \ldots & a_{mn} \end{array} \right] \ \ \left[ \begin{array}{c} b_1\ b_2\ b_3\ \vdots\ b_n \end{array} \right]
\left[ \begin{array}{c} a_{11}b_1+a_{12}b_2 + a_{13}b_3 + \cdots + a_{1n} b_n\ a_{21}b_1+a_{22}b_2 + a_{23}b_3 + \cdots + a_{2n} b_n\ \vdots\ a_{m1}b_1+a_{m2}b_2 + a_{m3}b_3 + \cdots + a_{mn} b_n\ \end{array} \right]. \end{align*}`$
NumLib's procedure for this task is called omvmmv ("mmv" = multiply a matrix with a vector):
procedure omvmmv(var a: ArbFloat; m, n, rwidth: ArbInt; var b, c: ArbFloat);Example
Calculate the product
$\begin{align*} \mathbf{c} = A\ \mathbf{b}= \left[ \begin{array}{cccc} 3 & 5 & 4 & 1 & -4\\ -2 & 3 & 4 & 1 & 0\\ 0 & 1 & -1 & -2 & 5 \end{array} \right] \ \ \left[ \begin{array}{c} 3\\ 0\\ -1\\ -2\\ 1 \end{array} \right] \end{align*}$
program matrix_vector_multiplication;

uses
  typ, omv;

const
  m = 3;
  n = 5;
  p = 4;

  A: array[1..m, 1..n] of ArbFloat = (
    ( 3,  5,  4,  1, -4),
    (-2,  3,  4,  1,  0),
    ( 0,  1, -1, -2,  5)
  );
  b: array[1..n] of ArbFloat = (
    3, 0, -1, -2, 1
  );

var
  c: array[1..m] of ArbFloat;
  i, j: Integer;

begin
  // Calculate product c = A b
  omvmmv(
    A[1,1], m, n, n,
    b[1],
    c[1]
  );

  // Print A
  WriteLn('A = ');
  for i:= 1 to m do begin
    for j := 1 to n do
      Write(A[i, j]:10:0);
    WriteLn;
  end;
  WriteLn;

  // Print vector b
  WriteLn('b = ');
  for i:= 1 to n do
    Write(b[i]:10:0);
  WriteLn;
  WriteLn;

  // Print result vector c
  WriteLn('c = A b = ');
  for i:= 1 to m do
    Write(c[i]:10:0);
  WriteLn;
end.
Transpose matrix
The transpose matrix A<sup>T</sup> of matrix A is obtained by flipping rows and columns:
$\begin{align*} {A} = \left[ \begin{array}{cccc} a_{11} & a_{12} & a_{13} & \ldots & a_{1n}\\ a_{21} & a_{22} & a_{23} & \ldots & a_{2n}\\ \vdots & \vdots & \vdots & \ddots & \vdots\\ a_{m1} & a_{m2} & a_{m3} & \ldots & a_{mn} \end{array} \right] \ \ \ {A^T} = \left[ \begin{array}{cccc} a_{11} & a_{21} & \ldots & a_{m1}\\ a_{12} & a_{22} & \ldots & a_{m2}\\ a_{13} & a_{23} & \ldots & a_{m3} \\ \vdots & \vdots & \ddots & \vdots \\ a_{1n} & a_{2n} & \ldots & a{mn} \end{array} \right] \end{align*}$
Use the procedure omvtrm to perform this operation with NumLib:
procedure omvtrm(
  var a: ArbFloat; m, n, rwa: ArbInt;
  var c: ArbFloat; rwc: ArbInt
);adenotes the first element of the input matrix A. The elements of this array are not changed by the procedure.mis the number of rows of matrix A.nis the number of columns of matrix A.rwais the number of allocated columns of A. This way the array of A can be larger than acutally needed.
cis the first element of the transposed matrix A<sup>T</sup>. It hasnrows andmcolumns.rwcis the number of allocated columns for the transposed matrix.
Example
Obtain the transpose of the 2x4 matrix
${A} = \left[ \begin{array}{cccc} 1 & 2 & 3 & 4 \\ 11 & 22 & 33 & 44 \end{array} \right]$
program transpose;

uses
  typ, omv;

const
  m = 2;
  n = 4;

  A: array[1..m, 1..n] of ArbFloat = (
    ( 1,  2,  3,  4),
    (11, 22, 33, 44)
  );

var
  C: array[1..n, 1..m] of ArbFloat;
  i, j: Integer;

begin
  // Transpose A
  omvtrm(
    A[1,1], m, n, n,
    C[1,1], m
  );

  // Print A
  WriteLn('A = ');
  for i:= 1 to m do begin
    for j := 1 to n do
      Write(A[i, j]:10:0);
    WriteLn;
  end;
  WriteLn;

  // Print C
  WriteLn('AT = ');
  for i:= 1 to n do begin
    for j := 1 to m do
      Write(C[i, j]:10:0);
    WriteLn;
  end;
end.
Norm of vectors and matrices
A norm is a function which assigns a positive "length" to a vector a or a matrix M.
In case of vectors, NumLib supports these norms:
- The 1-norm of a vector is defined as the sum of the absolute values of the vector components. It is also called "Taxicab" or "Manhattan" norm because it corresponds to the distance that a taxis has to drive in a rectangular grid of streets.
$\|a\|_1 = \sum_{i=1}^n |{a_i}|$
- The 2-norm (also: Euclidian norm) corresponds to the distance of point a from the origin.
$\|a\|_2 = \sqrt{\sum_{i=1}^n {a_i}^2}$
- The maximum infinite norm of a vector is the maximum absolute value of its components.
$\|a\|_\infty = \max({a_1}, {a_2}, ... {a_n})$
The norms of matrices, as implemented by NumLib, are usually defined by row or column vectors:
- The 1-norm of a matrix is the maximum of the absolute column sums:
$\|M\|_1 = \max_{1 \le j \le {n}} \sum_{i=1}^m|M_{ij}|$
- The maximum infinite norm of a matrix is the maximum of the absolute row sum.
$\|M\|_\infty = \max_{1 \le i \le\ m} \sum_{j=1}^n |M_{ij}|$
- Only the Frobenius norm is calculated by individual matrix elements. It corresponds to the 2-norm of vectors, only the sum runs over all matrix elements:
$\|M\|_F = \sqrt{\sum_{i=1}^m \sum_{j=1}^n {M_{ij}}^2}$
These are the NumLib procedure for calculation of norms:
function omvn1v(var a: ArbFloat; n: ArbInt): ArbFloat;               // 1-norm of a vector
function omvn1m(var a: ArbFloat; m, n, rwidth: ArbInt): ArbFloat;    // 1-norm of a matrix
function omvn2v(var a: ArbFloat; n: ArbInt): ArbFloat;               // 2-norm of a vector
function omvnfm(Var a: ArbFloat; m, n, rwidth: ArbInt): ArbFloat;    // Frobenius norm of a matrix
function omvnmv(var a: ArbFloat; n: ArbInt): ArbFloat;               // Maximum infinite norm of a vector
function omvnmm(var a: ArbFloat; m, n, rwidth: ArbInt): ArbFloat; // Maximum infinite norm of a matrixais the first element of the vector or matrix of which the norm is to be calculatedm, in case of a matrix norm, is the number of matrix rows.nis the number of vector elements in case of a vector norm, or the number of columns in case of a matrix norm.rwidth, in case of a matrix norm, is the allocated count of columns. This way a larger matrix can be allocated than actually needed.
Example
program norm;

uses
  typ, omv;

const
  n = 2;
  m = 4;
  a: array[0..m-1] of ArbFloat = (0, 1, 2, -3);
  b: array[0..m-1, 0..n-1] of Arbfloat = ((3, -1), (-2, 2), (0, -1), (2, 1));

var
  i, j: Integer;

begin
  Write('Vector a = [');
  for i:= Low(a) to High(a) do
    Write(a[i]:5:0);
  WriteLn('  ]');
  WriteLn('        1-norm of vector a: ', omvn1v(a[0], m):0:3);
  WriteLn('        2-norm of vector a: ', omvn2v(a[0], m):0:3);
  WriteLn('  maximum norm of vector a: ', omvnmv(a[0], m):0:3);
  WriteLn;

  WriteLn('Matrix b = ');
  for i:= 0 to m-1 do begin
    for j := 0 to n-1 do
      Write(b[i,j]:5:0);
    WriteLn;
  end;
  WriteLn('        1-norm of matrix b: ', omvn1m(b[0, 0], m, n, n):0:3);
  WriteLn('Forbenius norm of matrix b: ', omvnfm(b[0, 0], m, n, n):0:3);
  WriteLn('  maximum norm of matrix b: ', omvnmm(b[0, 0], m, n, n):0:3);

  ReadLn;
end.
Determinant of a matrix (unit det)
Unit det provides a series of routines for calculation of the determinant of a square matrix. Besides a procedure for general matrices there are also routines optimized for special matrix types (tridiagonal, symmetric).
In order to avoid possible overflows and underflows a factor may be split off during calculation, and the determinant is returned as a floating point number f times a multiplier 8<sup>k</sup>. In many cases, however, k = 0, and the determinant simply is equal to f.
Determinant of a standard matrix
The term "standard matrix" means here a matrix with is stored in the standard NumLib storage as described here, i.e. the matrix is stored as a 2D or 1D array of real numbers. The 2D array has at least n rows and n columns, the 1D array is dimensioned to contain at least n<sup>2</sup> elements.
Without making any assumptions on the properties of the matrix the determinant can be calculated by the procedure detgen. More efficient algorithms can be used, however, if the matrix has these particular properties:
- symmetric matrix --> use procedure
detgsy. - symmetric positive definite matrix --> use procedure
getgpd.
procedure detgen(n, rwidth: ArbInt; var a, f: ArbFloat; var k, term: ArbInt);    // --> generic matrix
procedure detgsy(n, rwidth: ArbInt; var a, f: ArbFloat; var k, term: ArbInt);    // --> symmetric matrix
procedure detgpd(n, rwidth: ArbInt; var a, f: ArbFloat; var k, term: ArbInt); // --> symmetric positive definite matrixndetermines the number of rows and columns of the input matrix (it must be square matrix).rwidthspecifies the allocated row length of the input matrix. This takes care of the fact that matrices can be allocated larger than actually needed.ais the first (i.e. top/left) element of the input matrix. The entire matrix must be contained within the same allocated memory block.fandkreturn the determinant of the matrix. The determinant is given by f * 8<sup>k</sup>. Usually k = 0, and the determinant simply is equal to f.
Example
Calculate the determinant of the 4x4 matrix
$A= \left[ \begin{array}{rrrr} 4 & 2 & 4 & 1 \\ 30 & 20 & 45 & 12 \\ 20 & 15 & 36 & 10 \\ 35 & 28 & 70 & 20 \end{array} \right]$
The matrix is positive definite because all elements are positive and the product b<sup>T</sup> A b cannot become zero or negative for any non-zero vector b. While the routine detgpd is the best for this matrix type the code below contains also commented-out calls to the other routines.
program determinant_spd_matrix;   // "spd" = symmetric positive definite

uses
  math, typ, det;

const
  n = 4;

const
  a: array[1..n, 1..n] of ArbFloat = (
    ( 4,  2,  4,  1)
    (30, 20, 45, 12)
    (20, 15, 36, 10)
    (35, 28, 70, 20)
  );

var
  f: ArbFloat;
  k: Integer;
  term: Integer = 0;
  i, j: Integer;

begin
  // write input matrix
  WriteLn('A = ');
  for i := 1 to n do begin
    for j := 1 to n do
      Write(a[i, j]:10:0);
    WriteLn;
  end;
  WriteLn;

  // Calculate determinant of symmetric positive definite matrix
  detgpd(n, n, a[1, 1], f, k, term);

  // or uncomment to use one of the other methods
  // detgen(n, n, a[1, 1], f, k, term);
  // detgsy(n, n, a[1, 1], f, k, term);

  if term = 1 then
    WriteLn('Determinant of A = ', f * intpower(8, k):0:9, ' (k = ', k, ')')
  else
    WriteLn('Incorrect input');
end.
Determinant of a band matrix
If a matrix has the shape of a band matrix then its determinant is best calculated by using the procedure detgba
procedure detgba(n, l, r: ArbInt; var a, f: ArbFloat; var k, term:ArbInt);ndenotes the number of columns and rows of the matrix (it must be square).lidentifies the left bandwidth, i.e. how many diagonals the band extends to the left, or below, the main diagonal.ridentifies the right bandwidth, i.e. how many diagons the band extends to the right, or above, the main diagonsl.aspecifies the first element of a 1D array which contains the elements of the diagonal band, see this. This array contains only the band elements and is obtained by running across the rows of the band matrix from left to right and top to bottom, starting at element A<sub>11</sub>. It must be dimensioned to contain at leastn*(l+1+r) - (r*(r+1)+l*(l+1)) div 2elements.fandkreturn the determinant of the matrix. The determinant is given by f * 8<sup>k</sup>. Usually k = 0, and the determinant simply is equal to f.
Example
Calculate the determinant of the 5x5 band matrix with left bandwidth l = 2 and right bandwidth r = 1
A = \begin{bmatrix}
    1 & 2 & 0 & 0 & 0 \\
    2 & 1 & 1 & 0 & 0 \\
    1 & 3 & 0 & 1 & 0 \\
    0 & 1 & 1 & 1 & 1 \\
    0 & 0 & 1 & 1 & 1
\end{bmatrix}program determinant_band_matrix;
uses
math, typ, det;
const
n = 5;
L = 2;
R = 1;
nelements = n*(L+1+R) - (R*(R+1) + L*(L+1)) div 2;
const
// Diagonal elements arranged in rows, elements outside of the band omitted!
a: array[1..nelements] of Arbfloat = (
1, 2,
2, 1, 1,
1, 3, 0, 1,
1, 1, 1, 1,
1, 1, 1
);
var
f: ArbFloat;
term: Integer = 0;
i, i1, i2, j, k: Integer;
begin
// Write diagonal elements
WriteLn('n = ', n);
Writeln('Left band width L = ', L);
WriteLn('Right band width R = ', R);
Write('Diagonal elements of A = ', a[1]:0:0);
for k := 2 to nelements do
Write(a[k]:5:0);
WriteLn;
WriteLn;
// write reconstructed band input matrix (not needed for calculation)
WriteLn('Reconstructed A = ');
k := 1;
for j := 1 to n do begin
i1 := j - L;
i2 := i1 + L + R;
for i:=1 to i1-1 do
Write(0.0:5:0);
for i := i1 to i2 do
if (i >= 1) and (i <= n) then begin
Write(a[k]:5:0);
inc(k);
end;
for i:= i2 + 1 to n do
if i <= n then
Write(0.0:5:0);
WriteLn;
end;
WriteLn;
// Calculate determinant
detgba(n, l, r, a[1], f, k, term);
if term = 1 then
WriteLn('Determinant of A = ', f * intpower(8, k):0:9, ' (k = ', k, ')')
else
WriteLn('Incorrect input');
end.Determinant of a symmetric positive definite band matrix
If a matrix has the shape of a band matrix and is symmetric positive definite then detgpb is the dedicated routine for calculation of its determinant.
procedure detgpb(n, w: ArbInt; var a, f: ArbFloat; var k, term:ArbInt);ndenotes the number of columns and rows of the matrix (it must be square).widentifies the bandwidth, i.e. how many diagonals the band extends to the left or to the right of the main diagonal. Left and right bandwidth must be equal.aspecifies the first element of a 1D array which contains the elements of the diagonal band, see this. This array contains only the left band elements and the elements of the main diagonal. It is obtained by running across the rows of the band matrix from left to right and top to bottom, but stopping at the main diagonal - the right band is ignored since it is equal to the left band. The array must be dimensioned to contain at leastn*(w+1) - (w*(w+1)) div 2elements.fandkreturn the determinant of the matrix. The determinant is given by f * 8<sup>k</sup>. Usually k = 0, and the determinant simply is equal to f.
Example
Calculate the determinant of the 7x7 symmetric band matrix with bandwidth w = 2 $A= \begin{bmatrix} 5 & -4 & 1 & & & & \\ -4 & 6 & -4 & 1 & & & \\ 1 & -4 & 6 & -4 & 1 & & \\ & 1 & -4 & 6 & -4 & 1 & \\ & & 1 & -4 & 6 & -4 & 1 \\ & & & 1 & -4 & 6 & -4 \\ & & & & 1 & -4 & 5 \end{bmatrix}$
program determinant_spd_band_matrix;     // "spd" = symmetric positive definite

uses
  math, typ, det;

const
  n = 7;
  w = 2;
  nelements = n * (w + 1) - (w * (w + 1)) div 2;

const
  // Band elements arragned in rows, elements outside of the band omitted!
  a: array[1..nelements] of Arbfloat = (
             5,
         -4, 6,
      1, -4, 6,
      1, -4, 6,
      1, -4, 6,
      1, -4, 6,
      1, -4, 5
    );

  function MatrixIndexToArrayIndex(i, j, n, w: Integer): Integer;

    function DiagElementIndex(i: Integer): Integer;
    var
      k: Integer;
    begin
      Result := 1;
      if i = 1 then
        exit;
      // Rows truncated at left
      for k := 2 to w do begin
        Result := Result + k;
        if k = i then
          exit;
      end;
      // full rows and those truncated at right
      for k := w+1 to n do begin
        Result := Result + w + 1;
        if k = i then
          exit;
      end;
      Result := n;
    end;

  var
    d: Integer;
  begin
    if j > i then begin
      Result := MatrixIndexToArrayIndex(j, i, n, w);
      exit;
    end;

    Result := DiagElementIndex(i);
    if (i = j) then
      exit;

    d := i - j;
    if d > w then
      Result := -1
    else begin
      dec(Result, d);
      if (Result < 1) then
        Result := -1
    end;
  end;

var
  i, j, k: Integer;
  f: ArbFloat;
  term: Integer = 0;
begin
  // Write diagonal elements
  WriteLn('n = ', n);
  Writeln('(One-sided) band width W = ', w);
  Write('Diagonal elements of A = ', a[1]:0:0);
  for k := 2 to nelements do
    Write(a[k]:3:0);
  WriteLn;
  WriteLn;

  // write reconstructed band input matrix (not needed for calculation)
  WriteLn('Reconstructed A = ');
  k := 1;
  for i := 1 to n do begin
    for j := 1 to n do begin
      k := MatrixIndexToArrayIndex(i, j, n, w);
      if k = -1 then
        Write(0.0:3:0)
      else
        Write(a[k]:3:0);
    end;
    WriteLn;
  end;
  WriteLn;

  // Calculate determinant
  detgpb(n, w, a[1], f, k, term);
  if term = 1 then
    WriteLn('Determinant of A = ', f * intpower(8, k):0:9, ' (k = ', k, ')')
  else
    WriteLn('Incorrect input');
end.
Determinant of a tridiagonal matrix
Calculation of the determinant of a tridiagonal matrix is done by the procedure detgtr:
procedure detgtr(n: ArbInt; var l, d, u, f: ArbFloat; var k, term:ArbInt);ndenotes the number of columns and rows of the matrix (it must be square).lspecifies the first element in the subdiagonal of the matrix. This 1D array must be dimensioned to at leastn-1elements.dspecifies the first element along the main diagonal of the matrix. This 1D array must be dimensioned to contain at leastnelements.uspecifies the first element along the superdiagonal of the matrix. The array must be dimensioned to have at leastn-1elements.fandkreturn the determinant of the matrix. The determinant is given by f * 8<sup>k</sup>. Usually k = 0, and the determinant simply is equal to f.
Example Calculate the determinant of the matrix
$A= \left( \begin{array}{rrrr} 1 & 1 & & \\ 2 & 1 & 1 & \\ & 1 & 1 & 0 \\ & & 1 & 2 \end{array} \right)$
program determinant_tridiagonal_matrix;

{$mode objfpc}{$H+}

uses
  math, typ, det;

const
  n = 4;

const
  u: array[0..n-2] of ArbFloat = (-1, -1, -1   );       // superdiagonal
  d: array[0..n-1] of ArbFloat = ( 2,  2,  2,  2);      // main diagonal
  l: array[1..n-1] of ArbFloat = (    -1, -1, -1);      // subdiagonal

var
  f: ArbFloat;
  k: Integer;
  term: Integer = 0;
  i, j: Integer;

begin
  // write input matrix
  WriteLn('A = ');
  for i := 0 to n-1 do begin
    for j := 0 to i-2 do
      Write(0.0:5:0);
    if i > 0 then
      Write(l[i]:5:0);
    Write(d[i]:5:0);
    if i < n-1 then
      Write(u[i]:5:0);
    for j:=i+2 to n-1 do
      Write(0.0:5:0);
    WriteLn;
  end;
  WriteLn;

  // Calculate determinant
  detgtr(n, l[1], d[0], u[0], f, k, term);
  if term = 1 then
    WriteLn('Determinant of A = ', f * intpower(8, k):0:9, ' (k = ', k, ')')
  else
    WriteLn('Incorrect input');

  ReadLn;

end.
Inverse of a matrix (unit inv)
Suppose a square matrix A. Then the matrix A<sup>-1</sup> is the inverse of A if the product A<sup>-1</sup> A is the identity matrix I (all elements zero, except for the diagonal elements which are 1).
The inverse matrix exists if the determinant of A is not zero.
$A^{-1} A = I = \begin{bmatrix} 1 & & 0 \\ & \ddots & \\ 0 & & 1 \end{bmatrix}$
NumLib provides various routines for calculation of the inverse matrix. Which algorithm is used depends on the properties of the matrix A. All routines discussed here have in common that the matrix is stored in the standard NumLib way, i.e. as a 2D array of real numbers with n rows and m columns, or as a 1D array with n m elements.
No special requirements are made for the matrix passed to invgen, except that it is square. The calculation in this routine is based on LU decomposition with partial pivoting. If the matrix is symmetric, it can be processed by invgsy which uses a reduction to tridiagonal form internally. A symmetric positive definite matrix can be passed to invgpd where the inverse is calculated by Cholesky decomposition.
procedure invgen(n, rwidth: ArbInt; var ai: ArbFloat; var term: ArbInt);   // --> generic matrix
procedure invgsy(n, rwidth: ArbInt; var ai: ArbFloat; var term: ArbInt);   // --> symmetric matrix
procedure invgpd(n, rwidth: ArbInt; var ai: ArbFloat; var term: ArbInt); // --> symmetric positive definite matrixnindicates the size of the matrix.rwidthis length of the rows of the two-dimensional array which holds the matrix. Normallyn = rwidth, but the matrix could have been declared larger than actually needed; in this caserwidthrefers to the declared size of the data array.aiis the first (top-left) element of the matrix in the data array. After the calculation the input data are overwritten by the elements of the inverse matrix in case of successful completion (term = 1); in other cases, the matrix elements are undefined.termprovides an error code:- 1 - successful completion, the elements of the inverse matrix can be found at the same place as the input matrix.
- 2 - the inverse could not be calculated because the input matrix is (almost) singular.
- 3 - incorrect input data,
n < 1.
Example
Calculate the inverse of the symmetric matrix $A = \left[ \begin{array}{rrrr} 5 & 7 & 6 & 5 \\ 7 & 10 & 8 & 7 \\ 6 & 8 & 10 & 9 \\ 5 & 7 & 9 & 10 \end{array} \right]$ This matrix is symmetric and positive definite (the product b<sup>T</sup> A b with any vector b = [b<sub>1</sub>, b<sub>2</sub>, b<sub>3</sub>]<sup>T</sup> cannot become zero or negative since all elements of this matrix are positive). Therefore, invgpd is best-suited for this task although the other routines can be used as well (uncomment their calls below).
program inverse_matrix;

uses
  typ, inv, omv;

const
  n = 4;
  D = 5;

var
  // a is the input matrix to be inverted
  // Note that this is matrix must be symmetric positive definite.
  a: array[1..n, 1..n] of ArbFloat = (
    (5,  7,  6,  5),
    (7, 10,  8,  7),
    (6,  8, 10,  9),
    (5,  7,  9, 10)
  );
  b: array[1..n, 1..n] of Arbfloat;
  c: array[1..n, 1..n] of ArbFloat;
  term: Integer = 0;
  i, j: Integer;

begin
  // write input matrix
  WriteLn('a = ');
  for i := 1 to n do begin
    for j := 1 to n do
      Write(a[i, j]:10:D);
    WriteLn;
  end;
  WriteLn;

  // Store input matrix because it will be overwritten by the inverse of a
  for i := 1 to n do
    for j := 1 to n do
      b[i, j] := a[i, j];

  // Calculate inverse  -- uncomment the procedure to be used.
  //invgen(n, n, a[1, 1], term);
  //invgsy(n, n, a[1, 1], term);
  invgpd(n, n, a[1, 1], term);

  // write inverse
  WriteLn('a^(-1) = ');
  for i := 1 to n do begin
    for j := 1 to n do
      Write(a[i, j]:10:D);
    WriteLn;
  end;
  WriteLn;

  // Check validity of result by multiplying inverse with saved input matrix
  omvmmm(a[1, 1], n, n, n,
         b[1, 1], n, n,
         c[1, 1], n);

  // write inverse
  WriteLn('a^(-1) x a = ');
  for i := 1 to n do begin
    for j := 1 to n do
      Write(c[i, j]:10:D);
    WriteLn;
  end;
end.
Solving systems of linear equations (unit sle)
A system of linear equations (or linear system) is a collection of two or more linear equations involving the same set of variables, x<sub>1</sub> ... x<sub>n</sub>.
$\begin{cases} a_{11} x_1 + a_{12} x_2 + \dots + a_{1n} x_n = b_1 \\ a_{21} x_1 + a_{22} x_2 + \dots + a_{2n} x_n = b_n \\ \ \ \ \vdots \\ a_{m1} x_1 + a_{m2} x_2 + \dots + a_{mn} x_n = b_m \end{cases}$
In order to find a solution which satisfies all equations simultaneously the system of equations is usually converted to a matrix equation A x = b, where
$A = \left [ \begin{array}{ccc} a_{11} & a_{12} & \dots & a_{1n} \\ a_{21} & a_{22} & \dots & a_{2n} \\ \vdots & \vdots & \ddots & \vdots \\ a_{m1} & a_{m2} & \dots & a_{mn} \end{array} \right ], \ \mathbf{x} = \left [ \begin{array}{c} x_1 \\ x_2 \\ \vdots \\ x_n \end{array} \right ], \ \mathbf{b} = \left [ \begin{array}{c} b_1 \\ b_2 \\ \vdots \\ b_m \end{array} \right ]$
NumLib offers several procedures to solve the matrix equation depending on the properties of the matrix.
Square matrices with standard storage
Here we describe several routines in which the matrix of the equation system is square, i.e. there are as many equations as unknowns. This matrix is assumed to be passed to the procedures in the standard NumLib way as the first element of a 2D or 1D array. The 2D array must be dimensioned to contain at least n rows and n columns, the 1D array must contain at least n<sup>2</sup> elements.
The most general procedure is slegen and applied to any square matrix A. The system is solved using the Gauss elimination procedure with partial pivoting.
If the matrix A is symmetric then the reduction to tridiagonal form generally is more stable. This is done in routine slegsy.
If A, furthermore, is a symmetric positive definite matrix, then the Cholesky method is best-suited. This is applied in routine slegpd.
procedure slegen(n, rwidth: ArbInt; var a, b, x, ca: ArbFloat; var term: ArbInt);   // generic matrix
procedure slegsy(n, rwidth: ArbInt; var a, b, x, ca: ArbFloat; var term: ArbInt);   // symmetric matrix
procedure slegpd(n, rwidth: ArbInt; var a, b, x, ca: ArbFloat; var term: ArbInt); // symmetric positive definite matrixnis the number of unknown variables. It must be the same as the number of columns and rows of the coefficent matrix.rwidthidentifies the allocated number of columns of the coefficient matrix. This is useful if the matrix is allocated larger than needed. It is required thatn <= rwidth.ais the first (i.e. top left) element of the coefficient matrix A; the other elements must follow within the same allocated memory block. The matrix will not be changed during the calculation.bis the first element of the array containing the constant vector b. The array length at least must be equal ton. The vector will not be changed during the calculation.xis the first element of the array to receive the solution vector x. It must be allocated to contain at leastnvalues.cais a parameter to describe the accuracy of the solution.termreturns an error code:- 1 - successful completion, the solution vector x is valid
- 2 - the solution could not have been determined because the matrix is (almost) singular.
- 3 - error in input values:
n < 1.
Example
Solve this system of linear equations:
$\begin{cases} 5 x_1 + 7 x_2 + 6 x_3 + 5 x_4 = 57 \\ 7 x_1 + 10 x_2 + 8 x_3 + 7 x_4 = 79 \\ 6 x_1 + 8 x_2 + 10 x_3 + 9 x_4 = 88 \\ 5 x_1 + 7 x_2 + 9 x_3 + 10 x_4 = 86 \end{cases} \qquad \Rightarrow \qquad A= \left[ \begin{array}{rrrr} 5 & 7 & 6 & 5 \\ 7 & 10 & 8 & 7 \\ 6 & 8 & 10 & 9 \\ 5 & 7 & 9 & 10 \end{array} \right] , \; \mathbf{b} = \left[ \begin{array}{r} 57 \\ 79 \\ 88 \\ 86 \end{array} \right]$
This matrix is symmetric positive definite. Therefore, all routines presented here can be applied. Uncomment the requested line in the code below. As a test the result vector x is multiplied to matrix A, and the result must equal the constant vector b.
program solve_sys_lin_eq;

uses
  typ, sle, omv;

const
  n = 4;
  A: array[1..n, 1..n] of ArbFloat = (
    ( 5,  7,  6,  5),
    ( 7, 10,  8,  7),
    ( 6,  8, 10,  9),
    ( 5,  7,  9, 10)
  );
  b: array[1..n] of ArbFloat = (
    57, 79, 88, 86
  );

var
  x: array[1..n] of ArbFloat;
  b_test: array[1..n] of ArbFloat;
  ca: ArbFloat;
  i, j: Integer;
  term: Integer;

begin
  WriteLn('Solve matrix system A x = b');
  WriteLn;

  // Print A
  WriteLn('Matrix A = ');
  for i:= 1 to n do begin
    for j := 1 to n do
      Write(A[i, j]:10:0);
    WriteLn;
  end;
  WriteLn;

  // Print b
  WriteLn('Vector b = ');
  for i:= 1 to n do
    Write(b[i]:10:0);
  WriteLn;
  WriteLn;

  // Solve - select one of these methods
  slegen(n, n, A[1, 1], b[1], x[1], ca, term);
//  slegsy(n, n, A[1, 1], b[1], x[1], ca, term);
//  slegpd(n, n, A[1, 1], b[1], x[1], ca, term);

  if term = 1 then begin
    WriteLn('Solution vector x = ');
    for i:= 1 to n do
      Write(x[i]:10:0);
    WriteLn;
    WriteLn;

    omvmmv(A[1,1], n, n, n, x[1], b_test[1]);

    WriteLn('Check result: A x = (must be equal to b)');
    for i:= 1 to n do
      Write(b_test[i]:10:0);
    WriteLn;
  end
  else
    WriteLn('Error');

  ReadLn;

end.
Band matrix
A special solution, slegba, is implemented for a band matrix, i.e. a matrix in which all elements are zero outside a band of width l below and of width r above the main diagonal.
procedure slegba(n, l, r: ArbInt; var a, b, x, ca: ArbFloat; var term:ArbInt);ndenotes the number of columns and rows of the matrix (it must be square).lidentifies the left bandwidth, i.e. the number of diagonals the band extends below (or to the left of) the main diagonal.ridentifies the right bandwidth, i.e. the number of diagonals the band extends abofe (or to the right of) the main diagonsl.aspecifies the first element of a 1D array which contains the elements of the diagonal band, see this. This array contains only the band elements and is obtained by running across the rows of the band matrix from left to right and top to bottom, starting at element A<sub>11</sub>. It must be dimensioned to contain at leastn*(l+1+r) - (r*(r+1)+l*(l+1)) div 2elements. Note that a 2D array cannot be used for this routine.bis the first element of the array containing the constant vector b. The array length at least must be equal ton. The vector will not be changed during the calculation.xis the first element of the array to receive the solution vector x. It must be allocated to contain at leastnvalues.cais a parameter to describe the accuracy of the solution.termreturns an error code:- 1 - successful completion, the solution vector x is valid
- 2 - the solution could not have been determined because the matrix is (almost) singular.
- 3 - error in input values:
n < 1,l < 0,l >= n,r < 0, orr >= n
Example
Solve this system of linear equations:
$\begin{array}{ccccccc} 5 x_1 & - & 4 x_2 & + & x_3 & & & & & & & & & = 0 \\ -4 x_1 & + & 6 x_2 & - & 4 x_3 & + & x_4 & & & & & & & = 0 \\ x_1 & - & 4 x_2 & + & 6 x_3 & - & 4 x_4 & & & & & & & = 0 \\ & & x_2 & - & 4 x_3 & + & 6 x_4 & - & 4 x_5 & & & & & = 1 \\ & & & & x_3 & - & 4 x_4 & + & 6 x_5 & - & 4 x_6 & + & x_7 & = 0 \\ & & & & & & x_4 & - & 4 x_5 & + & 6 x_6 & - & 4 x_7 & = 0 \\ & & & & & & & & x_5 & - & 4 x_6 & + & 5 x_7 & = 0 \\ \end{array} \qquad \Rightarrow \qquad A= \left[ \begin{array}{rrrr} 5 & -4 & 1 & 0 & 0 & 0 & 0 \\ -4 & 6 & -4 & 1 & 0 & 0 & 0 \\ 1 & -4 & 6 & -4 & 1 & 0 & 0 \\ 0 & 1 & -4 & 6 & -4 & 1 & 0 \\ 0 & 0 & 1 & -4 & 6 & -4 & 1 \\ 0 & 0 & 0 & 1 & -4 & 6 & -4 \\ 0 & 0 & 0 & 0 & 1 & -4 & 5 \end{array} \right] , \; \mathbf{b} = \left[ \begin{array}{r} 0 \\ 0 \\ 0 \\ 1 \\ 0 \\ 0 \\ 0 \end{array} \right]$
program solve_band;

uses
  typ, sle, omv;

const
  n = 7;
  L = 2;
  R = 2;
  nelements = n * (L + 1 + R) - (L * (L + 1) + R * (R + 1)) div 2;

  // Band elements arranged in rows, elements outside of the band omitted!
  a: array[1..nelements] of Arbfloat = (
             5, -4, 1,
         -4, 6, -4, 1,
      1, -4, 6, -4, 1,
      1, -4, 6, -4, 1,
      1, -4, 6, -4, 1,
      1, -4, 6, -4,
      1, -4, 5
    );
  b: array[1..n] of ArbFloat = (
    0, 0, 0, 1, 0, 0, 0
  );

var
  x: array[1..n] of ArbFloat;
  a_test: array[1..n, 1..n] of ArbFloat;
  b_test: array[1..n] of ArbFloat;
  ca: ArbFloat;
  i, j, k: Integer;
  term: Integer;

begin
  WriteLn('Solve matrix system A x = b where A is a band matrix');
  WriteLn;

  // Write diagonal elements
  WriteLn('Matrix A:');
  WriteLn('  n = ', n);
  Writeln('  Left band width L = ', L);
  WriteLn('  Right band width R = ', R);
  WriteLn('  Diagonal elements of A = ');
  for k := 1 to nelements do
    Write(a[k]:5:0);
  WriteLn;
  WriteLn;

  // Solve
  slegba(n, l, r, A[1], b[1], x[1], ca, term);

  if term = 1 then begin
    // To test the result we multiply A with the solution vector x and check
    // whether the result is equal to b.
    // Since mutliplication of a matrix stored like a band matrix is quite
    // cumbersome we copy the band matrix into a standard matrix.
    FillChar(a_test, SizeOf(a_test), 0);
    k := 1;
    for i:=1 to L do
      for j := i-L to i+R do
        if (j >= 1) and (j <= n) then begin
          a_test[i,j] := A[k];
          inc(k);
        end;

    for i:= L+1 to n-R do
      for j := i-L to i+R do begin
        a_test[i,j] := A[k];
        inc(k);
      end;
    for i := n-R+1 to n do
      for j := i-L to i+R do
        if j <= n then begin
          a_test[i,j] := A[k];
          inc(k);
        end;

    // Print A
    WriteLn('Matrix A =');
    for i:=1 to n do begin
      for j:=1 to n do
        Write(a_test[i,j]:5:0);
      WriteLn;
    end;
    WriteLn;

    // Print b
    WriteLn('Vector b = ');
    for i:= 1 to n do
      Write(b[i]:10:0);
    WriteLn;
    WriteLn;

    // Print solution
    WriteLn('Solution vector x = ');
    for i:= 1 to n do
      Write(x[i]:10:3);
    WriteLn;
    WriteLn;

    omvmmv(a_test[1,1], n, n, n, x[1], b_test[1]);

    WriteLn('Check result: A x = (must be equal to b)');
    for i:= 1 to n do
      Write(b_test[i]:10:0);
    WriteLn;
  end
  else
    WriteLn('Error');
end.
Symmetric positive definite band matrix
The optimized solution method for a symmetric positive band matrix is called slegpb.
procedure slegpb(n, w: ArbInt; var a, b, x, ca: ArbFloat; var term: ArbInt);ndenotes the number of columns and rows of the matrix (it must be square).widentifies the (one-sided) bandwidth, i.e. the number of diagonals the band extends below (or to the left of) the main diagonal. This is the same value as the number of diagonals the band extends above (or to the right of) the main diagonsl.aspecifies the first element of a 1D array which contains the elements of the diagonal band, see this. This array contains only the band elements and is obtained by running across the rows of the band matrix from left to right and top to bottom, starting at element A<sub>11</sub>, but stopping at the main diagonal. This means that the array contains only the left band and the main diagonal elements. It must be dimensioned to contain at leastn*(w+1) - (w*(w+1)) div 2elements. Note that a 2D array cannot be used for this routine.bis the first element of the array containing the constant vector b. The array length at least must be equal ton. The vector will not be changed during the calculation.xis the first element of the array to receive the solution vector x. It must be allocated to contain at leastnvalues. Iftermis not 1 then the solution array contains undefined data.cais a parameter to describe the accuracy of the solution.termreturns an error code:- 1 - successful completion, the solution vector x is valid
- 2 - the solution could not have been determined because the matrix is (almost) singular.
- 3 - error in input values:
n<1,w<0, orw>=n
Example
The matrix of the band matrix example is symmetrical positive definite. Therefore, procedure slegpb can be applied as well:
program solve_spd;    // "spd" = symmetric positive definite

uses
  typ, sle, omv;

const
  n = 7;
  w = 2;
  nelements = n * (w + 1) - (w * (w + 1)) div 2;

  // Band elements arranged in rows, elements outside of the band as well as right diagonals omitted!
  a: array[1..nelements] of Arbfloat = (
             5,
         -4, 6,
      1, -4, 6,
      1, -4, 6,
      1, -4, 6,
      1, -4, 6,
      1, -4, 5
    );
  b: array[1..n] of ArbFloat = (
    0, 0, 0, 1, 0, 0, 0
  );

var
  x: array[1..n] of ArbFloat;
  a_test: array[1..n, 1..n] of ArbFloat;
  b_test: array[1..n] of ArbFloat;
  ca: ArbFloat;
  i, j, k: Integer;
  term: Integer;

begin
  WriteLn('Solve matrix system A x = b where A is a symmetric positive definite band matrix');
  WriteLn;

  // Write diagonal elements
  WriteLn('Matrix A:');
  WriteLn('  n = ', n);
  Writeln('  (One-sided) band width w = ', w);
  WriteLn('  Diagonal elements of A = ');
  for k := 1 to nelements do
    Write(a[k]:5:0);
  WriteLn;
  WriteLn;

  // Solve
  slegpb(n, w, A[1], b[1], x[1], ca, term);

  if term = 1 then begin
    // To test the result we multiply A with the solution vector x and check
    // whether the result is equal to b.
    // Since mutliplication of a matrix stored like a band matrix is quite
    // cumbersome we copy the band matrix into a standard matrix.
    FillChar(a_test, SizeOf(a_test), 0);
    i := 1;
    k := 1;
    while (k <= nelements) and (i <= n) do begin
      for j := i - w to i do
        if (j >= 1) and (j <= n) then begin
          a_test[i, j] := a[k];
          a_test[j, i] := a[k];
          inc(k);
        end;
      inc(i);
    end;

    // Print A
    WriteLn('Matrix A =');
    for i:=1 to n do begin
      for j:=1 to n do
        Write(a_test[i,j]:5:0);
      WriteLn;
    end;
    WriteLn;

    // Print b
    WriteLn('Vector b = ');
    for i:= 1 to n do
      Write(b[i]:10:0);
    WriteLn;
    WriteLn;

    // Print solution
    WriteLn('Solution vector x = ');
    for i:= 1 to n do
      Write(x[i]:10:3);
    WriteLn;
    WriteLn;

    omvmmv(a_test[1,1], n, n, n, x[1], b_test[1]);

    WriteLn('Check result: A x = (must be equal to b)');
    for i:= 1 to n do
      Write(b_test[i]:10:3);
    WriteLn;
  end
  else
    WriteLn('Error');
end.
Tridiagonal matrix
NumLib offers two specialized procedures for solving a system of linear equations based on a tridiagonal matrix A. Both rely on the memory-optimized storage of tridiagonal matrices as described here. They differ in the internal calculation algorithm and in the behavior with critical matrices.
procedure sledtr(n: ArbInt; var l, d, u, b, x: ArbFloat; var term: ArbInt);
procedure slegtr(n: ArbInt; var l, d, u, b, x, ca: ArbFloat; var term: ArbInt);nis the number of unknown variables. It must be the same as the number of columns and rows of the coefficent matrix.lspecifies the first element in the subdiagonal of the matrix A. This 1D array must be dimensioned to at leastn-1elements.dspecifies the first element along the main diagonal of the matrix A. This 1D array must be dimensioned to contain at leastnelements.uspecifies the first element along the superdiagonal of the matrix A. The array must be dimensioned to have at leastn-1elements.bis the first element of the array containing the constant vector b. The array length at least must be equal ton. The vector will not be changed during the calculation.xis the first element of the array to receive the solution vector x. It must be allocated to contain at leastnvalues.cais a parameter to describe the accuracy of the solution.termreturns an error code:- 1 - successful completion, the solution vector x is valid
- 2 - the solution could not have been determined because the matrix is (almost) singular.
- 3 - error in input values:
n < 1.
sledtr is numerically stable if matrix A fulfills one of these conditions:
- A is regular (i.e. its inverse matrix exists), and A is columnar-diagonally dominant; this means:
- |d<sub>1</sub>| ≥ |l<sub>2</sub>|,
- |d<sub>i</sub>| ≥ |u<sub>i-1</sub>| + |*l<sub>i</sub>+1|,i= 2, ...,*n''-1,
- |d<sub>n</sub>| ≥ |u<sub>n-1</sub>|
- A is regular, and A is diagonally dominant; this means:
- |d<sub>1</sub>| ≥ |l<sub>2</sub>|,
- |d<sub>i</sub>| ≥ |u<sub>i</sub>| + |*l<sub>i</sub>|,i= 2, ...,*n''-1,
- |d<sub>n</sub>| ≥ |u<sub>n</sub>|
- A is symmetric and positive-definite.
However, this procedure does not provide the parameter ca from which the accuracy of the determined solution can be evaluated. If this is needed the (less stable) procedure slegtr must be used.
Example Solve this tridiagonal system of linear equations for n = 8:
$\begin{cases} 188 x_1 - 100 x_2 = 0 \\ -100 x_1 + 188 x_2 -100 x_3 = 0 \\ \vdots \\ -100 x_{n-2} + 188 x_{n-1} - 100 x_n = 0 \\ -100 x_{n-1} + 188 x_n = 0 \end{cases} \qquad \Rightarrow \qquad A= \left[ \begin{array}{rrrrr} 188 & -100 & & & 0 \\ -100 & 188 & -100 & & \\ & \ddots & \ddots & \ddots & \\ & & -100 & 188 & -100 \\ & & & -100 & 188 \\ \end{array} \right] , \; \mathbf{b} = \left[ \begin{array}{r} 88 \\ -12 \\ \vdots \\ -12 \\ 88 \end{array} \right]$
program solve_tridiag;

uses
  typ, sle;

const
  n = 8;
  u: array[1..n-1] of ArbFloat = (-100, -100, -100, -100, -100, -100, -100      );
  d: array[1..n] of ArbFloat   = ( 188,  188,  188,  188,  188,  188,  188,  188);
  l: array[2..n] of ArbFloat   = (      -100, -100, -100, -100, -100, -100, -100);
  b: array[1..n] of ArbFloat   = (  88,  -12,  -12,  -12,  -12,  -12,  -12,   88);

var
  A: array[1..n, 1..n] of ArbFloat;
  x: array[1..n] of ArbFloat;
  b_test: array[1..n] of ArbFloat;
  ca: ArbFloat;
  i, j: Integer;
  term: Integer;

begin
  WriteLn('Solve tridiagonal matrix system A x = b');
  WriteLn;

  Write('Superdiagonal of A:':25);
  for i := 1 to n-1 do
    Write(u[i]:10:0);
  WriteLn;

  Write('Main diagonal of A:':25);
  for i:= 1 to n do
    Write(d[i]:10:0);
  WriteLn;

  Write('Subdiagonal of A:':25);
  Write('':10);
  for i:=2 to n do
    Write(l[i]:10:0);
  WriteLn;

  Write('Vector b:':25);
  for i:=1 to n do
    Write(b[i]:10:0);
  WriteLn;

  // Solve
  slegtr(n, l[2], d[1], u[1], b[1], x[1], ca, term);
  { or:
  sledtr(n, l[2], d[1], u[1], b[1], x[1], term);
  }

  if term = 1 then begin
    Write('Solution vector x:':25);
    for i:= 1 to n do
      Write(x[i]:10:0);
    WriteLn;

    // Multiply A with x to test the result
    // NumLib does not have a routine to multiply a tridiagonal matrix with a
    // vector... Let's do it manually.
    b_test[1] := d[1]*x[1] + u[1]*x[2];
    for i := 2 to n-1 do
      b_test[i] := l[i]*x[i-1] + d[i]*x[i] + u[i]*x[i+1];
    b_test[n] := l[n]*x[n-1] + d[n]*x[n];

    Write('Check b = A x:':25);
    for i:= 1 to n do
      Write(b_test[i]:10:0);
    WriteLn;
  end
  else
    WriteLn('Error');
end.
Overdetermined systems (least squares)
Unlike the other routines in unit sle which require a square matrix A, slegls can solve linear systems described by a rectangular matrix which has more rows than colums, or speaking in terms of equations, has more equations than unknowns. Such a system generally is not solvable exactly. But an approximate solution can be found such that the sum of squared residuals of each equation, i.e. the norm $\|\mathbf{b} - A \mathbf{x}\|_2$ is as small as possible. The most prominent application of this technique is fitting of equations to data (regression analysis).
procedure slegls(var a: ArbFloat; m, n, rwidtha: ArbInt; var b, x: ArbFloat; var term: ArbInt);ais the first (i.e. top left) element of an array with the coefficient matrix A; the other elements must follow within the same allocated memory block. The array will not be changed during the calculation.mis the number of rows of the matrix A (or: the number of equations).nis the number of columns of the matrix A (or: the number of unknown variables). n must not be larger than m.rwidthidentifies the allocated number of columns of the coefficient matrix A. This is useful if the matrix is allocated larger than needed. It is required thatn <= rwidth.bis the first element of the array containing the constant vector b. The array length must correspond to the number of matrix rowsm, but the array can be allocated to be larger.xis the first element of the array to receive the solution vector x. The array length must correspond to the number of matrix columnsn, but the array can be allocated to be larger.termreturns an error code:- 1 - successful completion, the solution vector x is valid
- 2 - there is no unambiguous solution because the columns of the matrix are linearly dependant..
- 3 - error in input values:
n < 1, orn>m.
The method is based on reduction of the array A to upper triangle shape through Householder transformations.
Example
Find the least-squares solution for the system A x = b of 4 equations and 3 unknowns with
$A= \left( \begin{array}{rrr} 1 & 0 & 1 \\ 1 & 1 & 1 \\ 0 & 1 & 0 \\ 1 & 1 & 0 \end{array} \right), \ \ b= \left( \begin{array}{r} 21 \\ 39 \\ 21 \\ 30 \end{array} \right).$
program solve_leastsquares;

uses
  typ, sle, omv;

const
  m = 4;
  n = 3;

  A: array[1..m, 1..n] of ArbFloat = (
    (1, 0, 1),
    (1, 1, 1),
    (0, 1, 0),
    (1, 1, 0)
  );
  b: array[1..m] of ArbFloat = (
    21, 39, 21, 30);

var
  x: array[1..n] of ArbFloat;
  term: ArbInt;
  i, j: Integer;
  b_test: array[1..m] of ArbFloat;
  sum: ArbFloat;

begin
  WriteLn('Solve A x = b with the least-squares method');
  WriteLn;

  // Display input data
  WriteLn('A = ');
  for i := 1 to m do
  begin
    for j := 1 to n do
      Write(A[i, j]:10:0);
    WriteLn;
  end;
  WriteLn;
  WriteLn('b = ');
  for i := 1 to m do
    Write(b[i]:10:0);
  WriteLn;

  // Calculate and show solution
  slegls(a[1,1], m, n, n, b[1], x[1], term);

  WriteLn;
  WriteLn('Solution x = ');
  for j:= 1 to n do
    Write(x[j]:10:0);
  WriteLn;

  // Calculate and display residuals
  WriteLn;
  WriteLn('Residuals A x - b = ');
  sum := 0;
  omvmmv(a[1,1], m, n, n, x[1], b_test[1]);
  for i:=1 to m do begin
    Write((b_test[i] - b[i]):10:0);
    sum := sum + sqr(b_test[i] - b[i]);
  end;
  WriteLn;

  // Sum of squared residuals
  WriteLn;
  WriteLn('Sum of squared residuals');
  WriteLn(sum:10:0);

  WriteLn;
  WriteLn('----------------------------------------------------------------------------');
  WriteLn;

  // Modify solution to show that the sum of squared residuals increases';
  WriteLn('Modified solution x'' (to show that it has a larger sum of squared residuals)');
  x[1] := x[1] + 1;
  x[2] := x[2] - 1;
  WriteLn;
  for j:=1 to n do
    Write(x[j]:10:0);
  omvmmv(a[1,1], m, n, n, x[1], b_test[1]);
  sum := 0;
  for i:=1 to m do
    sum := sum + sqr(b_test[i] - b[i]);
  WriteLn;
  WriteLn;
  WriteLn('Sum of squared residuals');
  WriteLn(sum:10:0);
end.
Eigenvalues and eigenvectors (unit eig)
A vector is an eigenvector if it does not change its direction after a linear transformation has been applied to it. In matrix terms: if a non-zero vector x of dimension n is multiplied to a square nxn matrix A and the product is the same vector multiplied by a scalar λ then x is an eigenvector, and λ is called an eigenvalue:
$A \mathbf{x} = \lambda \mathbf{x} \qquad \Rightarrow \qquad A \mathbf{x} - \lambda \mathbf{x} = 0$
NumLib offers a variety of routines for calculation of eigenvectors and eigenvalues. They are optimized for the matrix type. Every matrix type will be supported by two or four procedures of various degree of complexity; they are identified by appended numbers 1 and 2, or 1 to 4:
- The procedures with appended 1 calculate all eigenvalues.
- The procedures with the appended 2 do the same but only for some eigenvalues which have an index in a specified range (λ<sub>k1</sub>...λ<sub>k2</sub> out of λ<sub>1</sub>...λ<sub>n</sub>).
- The procedures with the appended 3 calculate all eigenvalues and all eigenvectors.
- The procedures with the appended 4 do the same, but again return only some eigenvalues and eigenvectors having an index in the specified interval.
Matrices with general storage
The routines discussed here assume that the n x n matrix for which the eigenvalues are to be calculated is stored in the conventional way as a 2D (or 1D) array of ArbFloat values.
The NumLib method for determining the eigenvalues and eigenvectors of a generic matrix are called eigge1 and eigge3 ("ge" = "generic"). Optimized calculation schemes exists for generic symmetric matrices and symmetric positive definite matrices; the corresponding routines are called eiggs1, eiggs2, eiggs3, and eiggs4 for generic symmetric matrices ("gs" = "generic symmetric")., and eiggg1, eiggg2, eiggg3, eiggg4 for symmetric positive definite matrices ("gg" = ??)
// Generic matrix (without any special symmetries)
procedure eigge1(var a: ArbFloat; n, rwidth: ArbInt; var lam: complex; var term: ArbInt);                      // all eigenvalues
procedure eigge3(var a: ArbFloat; n, rwidtha: ArbInt; var lam, x: complex; rwidthx: ArbInt; var term: ArbInt); // all eigenvalues and eigenvectors

// Generic symmetric matrix
procedure eiggs1(var a: ArbFloat; n, rwidth: ArbInt; var lam: ArbFloat; var term: ArbInt);                     // all eigenvalues
procedure eiggs2(var a: ArbFloat; n, rwidth, k1, k2: ArbInt; var lam: ArbFloat; var term: ArbInt);             // some eigenvalues (index k1..k2)
procedure eiggs3(var a: ArbFloat; n, rwidtha: ArbInt; var lam, x: ArbFloat; var term: ArbInt);                 // all eigenvalues and eigenvectors
procedure eiggs4(var a: ArbFloat; n, rwidtha, k1, k2: ArbInt; var lam, x: ArbFloat; var term: ArbInt);         // some eigenvalues and eigenvectors (index k1..k2)

// Symmetric positive definite matrix
procedure eiggg1(var a: ArbFloat; n, rwidth: ArbInt; var lam: ArbFloat; var term: ArbInt);                     // all eigenvalues
procedure eiggg2(var a: ArbFloat; n, rwidth, k1, k2: ArbInt; var lam: ArbFloat; var term: ArbInt);             // some eigenvalues (index k1..k2)
procedure eiggg3(var a: ArbFloat; n, rwidtha: ArbInt; var lam, x: ArbFloat; var term: ArbInt);                 // all eigenvalues and eigenvectors
procedure eiggg4(var a: ArbFloat; n, rwidtha, k1, k2: ArbInt; var lam, x: ArbFloat; var term: ArbInt); // some eigenvalues and eigenvectors (index k1..k2)ais the first element of an array containing the matrix A for which the eigenvalue/eigenvector has to be calculated. The array must be dimensioned to provide space for at least n<sup>2</sup> floating point values.nspecifies the size of the matrix A, i.e. the number of rows or columns. Note that the input matrix must be square, i.e. the number of rows and columns is equal.rwidthis the allocated row length of the arraya. It can be larger than n if the array is allocated larger than necessary, but normallyrwidth = n.lamis the first element of an array receiving the calculated eigenvalues. In case of a generic matrix (eigge1,eigge2) the eigenvalues can be complex; therefore, the array must be dimensioned for values of typecomplexas declared in unit typ. In the other cases (eiggs1..4oreiggg1..4) the eigenvalues are real, and the array must be dimensioned for datatypeArbFloat. Since a nxn matrix has n eigenvalues the array must be allocated for at leastnvalues, in case of the procedures with appended 2 or 4 onlyk2-k1+1values are sufficient (see below).termreturns an error code:- 1 -- successful calculation
- 2 -- calculation failed
- 3 -- error in input data:
n<1,k1<1,k1>k2, ork2>n.
Additionally, in case of procedure eigge3, eigge4 , eiggg3 or eiggg4:
xis the first element of a matrix to receive the calculated eigenvectors. Again, the eigenvectors of a generic matrix can have complex components. Therefore, the matrix must be declared for the datatypecomplex, and it must be large enough to hold at least n<sup>2</sup> values, in case ofeigge4oreiggg4n * (k2-k1+1). If the matrix is symmetric or positive definite, the eigenvectors are real, and the array must be declared for datatypeArbFloat. In any case, the eigenvectors are normalized to unit length and arranged in the columns of this matrix.rwidthxdenotes the allocated row length of the matrixx. Thus it is possible to dimension the result matrix larger than actually needed.
Additionally, in case of procedures eiggs2, eiggs4, eiggg2 and eiggg4:
k1andk2define the interval of indexes k for which the eigenvalues (λ<sub>k</sub>) and eigenvalues (c<sub>k</sub>) are to be calculated. They are integers and must be ordered such that1<=k1<=k2<=n.
Example
Calculate the eigenvalues and eigenvectors of the matrix
$A= \begin{bmatrix} 8 & -1 & -5 \\ -4 & 4 & -2 \\ 18 & -5 & -7 \end{bmatrix}$
program eig_general_matrix;

uses
  SysUtils, math,
  typ, eig;

const
  n = 3;
  D = 3;

var
  // a is the input matrix
  a: array[1..n, 1..n] of ArbFloat = (
    ( 8, -1, -5),
    (-4,  4, -2),
    (18, -5, -7)
  );
  lambda: array[1..n] of complex;
  x: array[1..n, 1..n] of complex;
  term: Integer = 0;
  i, j: Integer;

  function ComplexToStr(z: complex; Decimals: Integer): String;
  var
    sgn: array[boolean] of string = ('+', '-');
  begin
    Result := Format('%.*f %s %.*fi', [Decimals, z.Re, sgn[z.Im < 0], Decimals, abs(z.Im)]);
  end;

begin
  // write input matrix
  WriteLn('a = ');
  for i := 1 to n do begin
    for j := 1 to n do
      Write(a[i, j]:10:D);
    WriteLn;
  end;
  WriteLn;

  // Calculate eigenvalues/vectors
  eigge3(a[1,1], n, n, lambda[1], x[1,1], n, term);

  // write eigenvalues
  WriteLn('Eigenvalues: lambda = ');
  for i := 1 to n do
    Write(ComplexToStr(lambda[i], D):25);
  WriteLn;
  WriteLn;

  // Write eigenvectors
  WriteLn('Eigenvectors (as columns): x = ');
  for i := 1 to n do begin
    for j := 1 to n do
      Write(ComplexToStr(x[i, j], D):25);
    WriteLn;
  end;
end.
Symmetric band matrices
NumLib provides four routines to calculate eigenvalues and eigenvectors of symmetric band matrices: eigbs1...eigbs4 ("bs" = band and symmetric):
// All eigenvalues
procedure eigbs1(var a: ArbFloat; n, w: ArbInt; var lam: ArbFloat; var term: ArbInt);

// Some eigenvalues (index k1..k2)
procedure eigbs2(var a: ArbFloat; n, w, k1, k2: ArbInt; var lam: ArbFloat; var term: ArbInt);

// All eigenvalues and all eigenvectors
procedure eigbs3(var a: ArbFloat; n, w: ArbInt; var lam, x: ArbFloat; rwidthx: ArbInt; var term: ArbInt);

// Some eigenvalues, some eigenvectors (index k1..k2)
procedure eigbs4(var a: ArbFloat; n, w, k1, k2: ArbInt; var lam, x: ArbFloat; rwidthx: ArbInt; var m2, term: ArbInt);aspecifies the first element of a 1D array which contains the diagonal elements of the left band and the main diagonal. It is obtained by running across the rows of the band matrix from left to right and top to bottom, but stopping at the main diagonal - the right band is ignored since it is equal to the left band. The array must be dimensioned to contain at leastn(w+1) - (w(w+1)) div 2 elements.ndenotes the number of columns and rows of the matrix (it must be square).widentifies the bandwidth, i.e. how many diagonals the band extends to the left or to the right of the main diagonal. Left and right bandwidth must be equal because the matrix is symmetric.lamis the first element of a real-valued array receiving the calculated eigenvalues. The eigenvalues of a symmetric matric are real values. Since an n x n matrix has n eigenvalues the array must be allocated for at least nArbFloatvalues.x, in case of routineseigbs3andeigbs4, is the first element of a matrix to receive the calculated eigenvectors. The matrix must be declared for the datatypeArbfloat, and it must be large enough to hold at least n x n values. The eigenvectors are normalized to unit length and are arranged in the columns of this matrix.rwidthx, in case of routineseigbs3andeigbs4, denotes the allocated row length of the matrix x. Thus it is possible to dimension the result matrix larger than actually needed.k1andk2, in case of procedureseigbs2andeigbs4, define the interval of indexes k for which the eigenvalues λ<sub>k</sub> and eigenvalues x<sub>k</sub> are to be calculated. They are integers and must be ordered such that1<=k1<=k2<=n.m2, in case of routineeigbs4, indicates the index of the largest eigenvalue for which an eigenvector has been calculated.termreturns an error code:- 1 -- successful calculation
- 2 -- calculation failed
- 3 -- error in input parameters:
n<1,w<0,w>=n,k1<1,k1>k2, ork2>n.
If the bandwidth w > n/3 then it is better to calculate all eigenvalues and eigenvectors even if not all of them are needed.
Example
Calculate the eigenvalues and eigenvectors of the symmetric 7 x 7 matrix $A= \begin{bmatrix} 5 & -4 & 1 & & & & 0 \\ -4 & 6 & -4 & 1 & & & \\ 1 & -4 & 6 & -4 & 1 & & \\ & 1 & -4 & 6 & -4 & 1 & \\ & & 1 & -4 & 6 & -4 & 1 \\ & & & 1 & -4 & 6 & -4 \\ 0 & & & & 1 & -4 & 5 \end{bmatrix}$ The eigenvalues are $\lambda_k = 16\sin^{4}\frac{k\pi}{16}, \qquad k=1,2,\ldots,7$
program eig_symmband_matrix;

uses
  SysUtils, math,
  typ, eig;

const
  n = 7;
  w = 2;
  nelements = n * (w + 1) - (w * (w + 1)) div 2;
  D = 3;

  // a contains the elements of the left and main diagonals of the input matrix
  a: array[1..nelements] of ArbFloat = (
     5,
    -4,  6,
     1, -4,  6,
         1, -4,  6,
             1, -4,  6,
                 1, -4, 6,
                     1, -4, 5 );

  function MatrixIndexToArrayIndex(i, j, n, w: Integer): Integer;

    function DiagElementIndex(i: Integer): Integer;
    var
      k: Integer;
    begin
      Result := 1;
      if i = 1 then
        exit;
      // Rows truncated at left
      for k := 2 to w do begin
        Result := Result + k;
        if k = i then
          exit;
      end;
      // full rows and those truncated at right
      for k := w+1 to n do begin
        Result := Result + w + 1;
        if k = i then
          exit;
      end;
      Result := n;
    end;

  var
    d: Integer;
  begin
    if j > i then begin
      Result := MatrixIndexToArrayIndex(j, i, n, w);
      exit;
    end;

    Result := DiagElementIndex(i);
    if (i = j) then
      exit;

    d := i - j;
    if d > w then
      Result := -1
    else begin
      dec(Result, d);
      if (Result < 1) then
        Result := -1
    end;
  end;

var
  lambda: array[1..n] of ArbFloat;
  x: array[1..n, 1..n] of ArbFloat;
  term: Integer = 0;
  i, j, k: Integer;

begin
  // Write diagonal elements
  WriteLn('n = ', n);
  Writeln('(One-sided) band width w = ', w);
  Write('Diagonal elements of A = ', a[1]:0:0);
  for k := 2 to nelements do
    Write(a[k]:3:0);
  WriteLn;
  WriteLn;

  // write reconstructed band input matrix (not needed for calculation)
  WriteLn('Reconstructed A = ');
  k := 1;
  for i := 1 to n do begin
    for j := 1 to n do begin
      k := MatrixIndexToArrayIndex(i, j, n, w);
      if k = -1 then
        Write(0.0:3:0)
      else
        Write(a[k]:3:0);
    end;
    WriteLn;
  end;
  WriteLn;

  // Calculate eigenvalues/vectors
  eigbs3(a[1], n, w, lambda[1], x[1,1], n, term);
  if term <> 1 then begin
    WriteLn('term = ', term, ' --> ERROR');
    halt;
  end;

  // Write expected results of eigenvalues
  WriteLn('Expected eigenvalues:');
  for i := 1 to n do
    Write(16 * intpower(sin(i*pi/16), 4):15:D);
  WriteLn;
  WriteLn;

  // write eigenvalues
  WriteLn('Calculated eigenvalues: lambda = ');
  for i := 1 to n do
    Write(lambda[i]:15:D);
  WriteLn;
  WriteLn;

  // Write eigenvectors
  WriteLn('Eigenvectors (as columns): x = ');
  for i := 1 to n do begin
    for j := 1 to n do
      Write(x[i, j]:15:D);
    WriteLn;
  end;
end.
Symmetric tridiagonal matrices
This type of matrices is treated best by the routines eigts1..eigts4:
// All eigenvalues
procedure eigts1(var d, cd: ArbFloat; n: ArbInt; var lam: ArbFloat; var term: ArbInt);

// Some eigenvalues (with indices k1..k2)
procedure eigts2(var d, cd: ArbFloat; n, k1, k2: ArbInt; var lam: ArbFloat; var term: ArbInt);

// All eigenvalues and all eigenvectors
procedure eigts3(var d, cd: ArbFloat; n: ArbInt; var lam, x: ArbFloat; rwidth: ArbInt; var term: ArbInt);

// Some eigenvalues and eigenvectors (with indices k1..k2)
procedure eigts4(var d, cd: ArbFloat; n, k1, k2: ArbInt; var lam, x: ArbFloat; rwidth: ArbInt; var m2, term: ArbInt);dspecifies the first element along the main diagonal of the matrix. This 1D array must be dimensioned to contain at leastnelements.cspecifies the first element in the subdiagonal of the matrix. This 1D array must be dimensioned to at leastn-1elements.ndenotes the number of columns or rows of the matrix (it must be square).k1andk2define the interval of indexes k for which the eigenvalues (λ<sub>k</sub>) and eigenvalues (c<sub>k</sub>) are to be calculated. They are integers and must be ordered such that1<=k1<=k2<=n.lamis the first element of an array receiving the calculated eigenvalues. Since there are n real eigenvalues the array must be dimensioned to contain at least n values of typeArbFloat. In case of the routines with appended 2 and 4, it is sufficient to provide space only fork2 - k1 + 1values.xis the first element of an array to receive the calculated eigenvectors. Since the eigenvectors are real the array must be prepared for data typeArbFloat. In case of routineeigts3, the array must be dimensioned for at least n<sup>2</sup> elements, in case of routineeigts4it must provide space for at leastn * (k2-k1+1)values. The eigenvectors are normalized to unit length and arranged in the columns of this matrix.rwidthxdenotes the allocated row length of the matrixx. Thus it is possible to dimension the result matrix larger than actually needed.termreturns an error code:- 1 -- successful calculation
- 2 -- calculation failed
- 3 -- error in input data:
n<1,k1<1,k1>k2, ork2>n.
Example
Calculate eigenvalues and eigenvectors of the matrix $A= \begin{bmatrix} 1 & 1 & 0 & 0 \\ 1 & 1 & 2 & 0 \\ 0 & 2 & 1 & 1 \\ 0 & 0 & 1 & 1 \end{bmatrix}$ The expected eigenvalues are $-\sqrt{2},\ 2-\sqrt{2},\ \sqrt{2},\ 2+\sqrt{2}$
program eig_symmtridiag_matrix;

uses
  typ, eig;

const
  n = 4;

  // a contains the elements of the main diagonal of the input matrix
  d: array[1..n] of ArbFloat = (1, 1, 1, 1);
  // c contains the elements of the subdiagonal
  c: array[2..n] of ArbFloat = (1, 2, 1);

var
  lambda: array[1..n] of ArbFloat;
  x: array[1..n, 1..n] of ArbFloat;
  term: Integer = 0;
  i, j, k: Integer;

begin
  // Write diagonals elements
  WriteLn('n = ', n);
  Write('Elements of main diagonal = ', d[1]:0:0);
  for k := 2 to n do
    Write(d[k]:3:0);
  WriteLn;
  Write('Elements of subdiagonal   = ', ' ':3, c[2]:0:0);
  for k := 3 to n do
    Write(c[k]:3:0);
  WriteLn;
  WriteLn;

  // write reconstructed band input matrix (not needed for calculation)
  WriteLn('Reconstructed A = ');
  for i := 1 to n do begin
    for j := 1 to n do begin
      if j = i then
        Write(d[i]:3:0)
      else if (j = i-1) then
        Write(c[i]:3:0)
      else if (j = i+1) then
        Write(c[i+1]:3:0)
      else
        Write(0.0:3:0);
    end;
    WriteLn;
  end;
  WriteLn;

  // Calculate eigenvalues/vectors
  eigts3(d[1], c[2], n, lambda[1], x[1,1], n, term);
  if term <> 1 then begin
    WriteLn('term = ', term, ' --> ERROR');
    halt;
  end;

  // Write expected results of eigenvalues
  WriteLn('Expected eigenvalues:');
  Write(-sqrt(2):15:3, 2-sqrt(2):15:3, sqrt(2):15:3, 2+sqrt(2):15:3);
  WriteLn;
  WriteLn;

  // write eigenvalues
  WriteLn('Calculated eigenvalues: lambda = ');
  for i := 1 to n do
    Write(lambda[i]:15:3);
  WriteLn;
  WriteLn;

  // Write eigenvectors
  WriteLn('Eigenvectors (as columns): x = ');
  for i := 1 to n do begin
    for j := 1 to n do
      Write(x[i, j]:15:3);
    WriteLn;
  end;
end.
Finding the roots of a function (unit roo)
The roots are the x values at which a function f(x) is zero.
Roots of a polynomial
A polynomial of degree n
z^n + a_1 z^{n-1} + a_2 z^{n-2} + ... + a_{n-1} z + a_n = 0always has n, not necessarily distinct, complex solutions. The datatype complex has been described in section complex numbers. These roots can be calculated by the function roopol:
procedure roopol(var a: ArbFloat; n: ArbInt; var z: complex; var k, term: ArbInt);ais the first element of an array containing the polynomial coefficients. Note that it is assumed that the polynomial has been normalized such that the coefficient of the highest-degree term is 1; this coefficient is not contained in the array. Therefore, the array must be dimensioned for at least n values. Since only real polynomials are handled here the array elements must be of datatypeArbFloat. The polynomial coefficients must be ordered from highest to lowest degree. Note that the data organization of the array is different from other polynomial routines in this library.nis the degree of the polynomial. Must be a positive integer.zis the first element in an array ofcomplexvalues which returns the roots of the polynomial. The array must be dimensioned to contain at least n values. The returned values are undefined if an error had occurred (term<> 1).kreturns how many roots were found. Always must be equal to n, otherwise an error has occured.termreturns an error code:- 1 -- sucessful completion, the result array contains valid data.
- 2 -- Not all roots could be detected, i.e.
k < n. - 3 -- Error in input data:
n < 1.
Example
Calculate the roots of the polynomial z<sup>5</sup> + 3 z<sup>4</sup> + 4 z<sup>3</sup> - 8 z<sup>2</sup>. The expected zero points are:
z_1=0,\ z_2=0,\ z_3=1,\ z_4=-2+2i,\ z_5=-2-2iprogram polynomial;
uses
SysUtils, typ, roo;
const
n = 5;
a: array[1..n] of ArbFloat = (3, 4, -8, 0, 0);
var
z: array[1..n] of complex;
k: ArbInt;
term: ArbInt;
i: Integer;
c: complex;
function ComplexToStr(z: complex; Decimals: Integer): string;
const
SIGN: array[boolean] of string = ('+', '-');
begin
Result := Format('%.*f %s %.*f i', [Decimals, z.re, SIGN[z.im <0], Decimals, abs(z.im)]);
end;
begin
// Solve equation
roopol(a[1], n, z[1], k, term);
if term = 1 then begin
// Display results
WriteLn('Results of procedure roopol:');
for i:=1 to n do
WriteLn(' Solution #', i, ': ', ComplexToStr(z[i], 6):20);
WriteLn;
// Display expected results
Writeln('Expected results:');
c.Init(0, 0); // z1 = 0
WriteLn(' Solution #1: ', complexToStr(c, 6):20);
c.Init(0, 0); // z2 = 0
WriteLn(' Solution #2: ', complexToStr(c, 6):20);
c.Init(1, 0); // z3 = 1
WriteLn(' Solution #3: ', complexToStr(c, 6):20);
c.Init(-2, +2); // z4 = -2 + 2 i
WriteLn(' Solution #4: ', complexToStr(c, 6):20);
c.Init(-2, -2); // z4 = -2 - 2 i
WriteLn(' Solution #5: ', complexToStr(c, 6):20);
end else
WriteLn('ERROR');
end.Roots of the quadratic equation
The quadratic equation
${z}^2 + {p} {z} + {q} = 0$
is a special polynomal of degree 2. It always has two, not necessarily different, complex roots. These solutions can be determined by the procedure rooqua.
procedure rooqua(p, q: ArbFloat; var z1, z2: complex);pandqare the (real) coefficients of the quadratic equationz1andz2return the two complex roots. See unit typ for the declaration of the typecomplex
Note that rooqua assumes that the coefficient of the quadratic term has been normalized to be 1.
Example
Determine the roots of the equation z<sup>2</sup> + 2 z + 5 = 0.
program quadratic_equ;

uses
  SysUtils, typ, roo;

var
  z1, z2: complex;

const
  SIGN: array[boolean] of string = ('+', '-');

begin
  rooqua(2, 5, z1, z2);

  WriteLn(Format('1st solution: %g %s %g i', [z1.re, SIGN[z1.im < 0], abs(z1.im)]));
  WriteLn(Format('2nd solution: %g %s %g i', [z2.re, SIGN[z2.im < 0], abs(z2.im)]));
end.
Roots of the binomial equation
The equation
z^n = ais another special polynomial in which all terms except for the highest- and lowest-order terms have zero coefficients. It has n complex solutions which can be calculated by the procedure roobin:
procedure roobin(n: ArbInt; a: complex; var z: complex; var term: ArbInt);nis the exponent in the binomial equation used. n must be a positive integer.ais the constant term a at the right side of the binomial equation. It is expected to be a complex value (see section on complex numbers).zis the first element of an array of data typecomplexto receive the results of the procedure. It must be dimensioned for at least ncomplexvalues.termreturns an error code:- 1 -- successful termination
- 2 -- error in input data:
n < 1
Example
Calculate the roots of the equation
z^4 = -1The exact solutions are
z_1 = \frac{1}{2} \sqrt{2} (1+i) ,\ z_2 = \frac{1}{2} \sqrt{2} (1-i) ,\ z_3= \frac{1}{2} \sqrt{2} (-1+i) ,\ z_4= \frac{1}{2} \sqrt{2} (-1-i)program binomial;
uses
SysUtils, typ, roo;
const
n = 4;
var
z: array[1..n] of complex;
term: ArbInt;
i: Integer;
a: complex;
c: complex;
function ComplexToStr(z: complex; Decimals: Integer): string;
const
SIGN: array[boolean] of string = ('+', '-');
begin
Result := Format('%.*g %s %.*g i', [Decimals, z.re, SIGN[z.im < 0], Decimals, abs(z.im)]);
end;
begin
// Prepare constant term as a complex value
a.Init(-1, 0);
// Solve equation
roobin(n, a, z[1], term);
if term = 1 then begin
// Display results
WriteLn('Results of procedure roobin:');
for i:=1 to n do
WriteLn(' Solution #', i, ': ', ComplexToStr(z[i], 6):20);
WriteLn;
// Display expected results
Writeln('Expected results:');
c.Init(1, 1);
c.Scale(0.5*sqrt(2));
WriteLn(' Solution #1: ', complexToStr(c, 6):20);
c.Init(1, -1);
c.Scale(0.5*sqrt(2));
WriteLn(' Solution #2: ', complexToStr(c, 6):20);
c.Init(-1, 1);
c.Scale(0.5*sqrt(2));
WriteLn(' Solution #3: ', complexToStr(c, 6):20);
c.Init(-1, -1);
c.Scale(0.5*sqrt(2));
WriteLn(' Solution #4: ', complexToStr(c, 6):20);
end else
WriteLn('ERROR');
end.Bisection
In the bisection method two x values a and b are estimated to be around the expected root such that the function values have opposite signs at a and b. The center point of the interval is determined, and the subinterval for which the function has opposite signs at its endpoints is selected for a new iteration. The process ends when a given precision, i.e. interval length, is achieved.
In NumLib, this approach is supported by the procedure roof1r:
procedure roof1r(f: rfunc1r; a, b, ae, re: ArbFloat; var x: ArbFloat; var term: ArbInt);fis the function for which the root is to be determined. It must be a function of one floating point argument (typeArbFloat). The type of the function,rfunc1r, is declared in unittyp.aandbare the endpoints of the test interval. The root must be located between these two values, i. e. the function values f(a) and f(b) must have different signs.aeandredetermine the absolute and relative precision, respectively, with which the root will be determined.reis relative to the maximum of abs(a) and abs(b). Note that precision and speed are conflicting issues. Highest accuracy is achieved ifaeis given asMachEps(see unittyp). Both parameters must not be negative.xreturns the value of the found root.termreturns whether the process has been successful:- 1 - successful termination, a zero point has been found with absolute accuracy
aeor relative accuracyre - 2 - the required accuracy of the root could not be reached; However, the value of x is called the "best achievable" approach
- 3 - error in input parameters:
ae< 0 orre< 0, or *f(a)**f(b) > 0
- 1 - successful termination, a zero point has been found with absolute accuracy
Example
The following program determines the square root of 2. This is the x value at which the function f(x) = x^2 - 2 is zero. Since f(1) = 1^2 - 2 = -1 < 0 and f(2) = 2^2 - 2 = 2 > 0 we can assume a and b to be 1 and 2, respectively.
program bisection_demo;

uses
  typ, roo;

function f(x: ArbFloat): ArbFloat;
begin
  Result := x*x - 2;
end;

var
  x: ArbFloat = 0.0;
  term : ArbInt;

begin
  roof1r(@f, 1.0, 2.0, 1e-9, 0, x, term);
  WriteLn('Bisection result ', x);
  WriteLn('sqrt(2)          ', sqrt(2.0));
end.
Roots of a system of nonlinear equations
Procedure roofnr finds the roots of a system of (nonlinear) equations:
$f_{i}(x_1,x_2,\ldots,x_n)=0, \; i=1,2,\ldots,n$
procedure roofnr(f: roofnrfunc; n: ArbInt; var x, residu: ArbFloat; ra: ArbFloat; var term: ArbInt);fcontains the address of the procedure that calculates the function values f<sub>i</sub>(x<sub>1</sub>, x<sub>2</sub>, ..., x<sub>n</sub>). The type of the function,roofnrfunc, is declared in unit typ to be
  type
    roofnrfunc = procedure(var x, fx: ArbFloat; var deff: boolean);
:* Here, x is the first element of an array of at least n ArbFloat values which provides the x<sub>j</sub> values at which the functions are to be calculated.
:* fx is the first element of another array of n ArbFloat values to receive the result of each function f<sub>i</sub>. Suppose, we want to solve the following system of equations
$\begin{array}{l} f_1(x_1, x_2) = x_1^2 + x_2^2 - 2 = 0 \\ f_2(x_1, x_2) = -(x_1 - 1)^2 + x_2 = 0 \end{array}$
Then the function to be used as f can be written like this:
    procedure func(var x1, f1x: real; var deff: boolean);
    var
      x: array[1..2] of real absolute x1;
      f: array[1..2] of real absolute f1x;
    begin
      f[1] := sqr(x[1]) + sqr(x[2]) - 2;
      f[2] := -sqr(x[1] - 1) + x[2];
    end;
:* The boolean parameter deff provides a way to stop the root finding process if some condition is met. The above example has two solutions, namely the intersection of a circle with a parabola. If only the intersection with x[1] >= 1 is requested then the process can be stopped as soon as a value x[1] < 1 is reached by setting deff to false:
    procedure func(var x1, f1x: real; var deff: boolean); far;
    var
      x: array[1..2] of real absolute x1;
      f: array[1..2] of real absolute f1x;
    begin
      deff := x[1] >= 1;
      if deff then begin
        f[1] := sqr(x[1]) + sqr(x[2]) - 2;
        f[2] := -sqr(x[1] - 1) + x[2];
      end;
end;nis the number of equations or independent x values (x<sub>i</sub>) in the system. Both must be the same.xis the first element of an array of at least nArbFloatvalues which serves for both input and output. On input the array must contain estimates of the roots to be used as starting points of the iterative calculation. On output, the array is overwritten with the zero points found. Inspect the returned value oftermto decide whether the output array contains a valid solution.residuis the 2-norm of the vector of residuals in the calculated solution
$\|f\|_2 = \sqrt{\Sigma_{i=1}^{n} f_i^2}$
racontains the relative accuracy with which the desired solution is to be calculated. Recommended values: 10<sup>-3</sup>, 10<sup>-5</sup>, 10<sup>-8</sup> ifArbFloatissingle,real, ordouble.termreturns an error code:- 1 -- successfull completion, a solution has been found with the desired accuracy
- 2 -- the desired accuracy could not be reached, the returned values of x are the best ones achievable.
- 3 -- Incorrect input data:
n < 0, orre < 0 - 4 -- The calculation process has been stopped because an internal limit for the count of function calls has been reached. Retry with other starting values for x.
- 5 -- Not enough progess, there may be no solution at all. If the solution is close to 0 choose another starting value.
- 6 -- The procedure wants to calculate a value outside the range defined by
deff.
Example
Calculate a solutions of the equation system
$\begin{array}{l} f_1(x_1, x_2) = x_1^2 + x_2^2 - 2 = 0 \\ f_2(x_1, x_2) = -(x_1 - 1)^2 + x_2 = 0 \end{array}$
program nonlinsystem;

uses
  SysUtils, typ, roo;

const
  n = 2;
  ra = 1e-10;

var
  x: array[1..n] of ArbFloat;
  f_check: array[1..n] of ArbFloat;
  residu: ArbFloat;
  i: Integer;
  term: Integer;
  deff: Boolean;

  procedure funcs(var x0, fx: ArbFloat; var deff: boolean);
  var
    xloc: array[1..n] of ArbFloat absolute x0;
    f: array[1..n] of ArbFloat absolute fx;
    x, y, z: ArbFloat;
  begin
    x := xloc[1];
    y := xloc[2];
    f[1] :=  sqr(x) + sqr(y) - 2;
    f[2] := -sqr(x - 1) + y;
  end;

begin
  // Initial guessed values
  x[1] := 0;
  x[2] := 0;

  // Solve equation
  roofnr(@funcs, n, x[1], residu, ra, term);

  WriteLn('term = ', term);
  WriteLn;

  if term in [1, 2] then begin
    // Display results
    WriteLn('Results found by procedure roofnr:');
    for i:=1 to n do
      WriteLn('Solution #' + IntToStr(i)+': ':20, x[i]:0:6);
    WriteLn;

    WriteLn('Norm of residuals: ', residu:0:15);
    WriteLn;

    // Test functions:
    f(x[1], f_check[1], deff);
    WriteLn('Check if the function values really are 0 at the found roots:');
    for i := 1 to n do
      WriteLn('Function #' + IntToStr(i) + ': ':20, f_check[i]:0:15);
  end else
    WriteLn('ERROR');

  ReadLn;
end.
Numerical integration of a function (unit int)
The NumLib function int1fr calculates the integral of a given function between limits a and b with a specified absolute accuracy ae:
procedure int1fr(f: rfunc1r; a, b, ae: ArbFloat; var integral, err: ArbFloat; var term: ArbInt);fpoints to the function to be integrated. It must be a function of a single real variable (typeArbFloat) and return anArbfloat. See the typerfunc1rdeclared in unit typ.a, bare the limits of integration.aand/orbcan attain the values+/-Infinityfor integrating over an infinite interval. The order ofaandbis handled in the mathematically correct sense.aedetermines the absolute accuracy requested.integrealreturns the value of the integral. It is only valid ifterm = 1.errreturns the achieved accuracy if the specified accuracy could not be reached.termhas the value 2 in this case.termreturns an error code:- 1 - successful termination, the integral could be calculated with absolute accuracy
ae. - 2 - the requested accuracy could not be reached. But the integral is approximated within the accuracy
err. - 3 - incorrect input data:
ae < 0, ora = b = infinity, ora = b = -infinity - 4 - the integral could not be calculated: divergence, or too-slow convergence.
- 1 - successful termination, the integral could be calculated with absolute accuracy
Example
Calculate the integral
$\int_a^b \frac 1 {x^2} \mathrm{d}x$
for several integration limits a and b. Since the function diverges at x = 0 the interval from a to b must not contain this point. The analytic result is $-1/{b} + 1/{a}$
program integrate;

uses
  SysUtils, typ, int;

function recipx2(x: ArbFloat): ArbFloat;
begin
  Result := 1.0 / sqr(x);
end;

function integral_recipx2(a, b: ArbFloat): Arbfloat;
begin
  if a = 0 then
    a := Infinity
  else if a = Infinity then
    a := 0.0
  else
    a := -1/a;
  if b = 0 then
    b := Infinity
  else if b = Infinity then
    b := 0.0
  else
    b := -1/b;
  Result := b - a;
end;

procedure Execute(a, b: ArbFloat);
var
  err: ArbFloat = 0.0;
  term: ArbInt = 0;
  integral: ArbFloat = 0.0;
begin
  try
    int1fr(@recipx2, a, b, 1e-9, integral, err, term);
  except
    term := 4;
  end;
  Write('  The integral from ' + FloatToStr(a) + ' to ' + FloatToStr(b));
  case term of
    1: WriteLn(' is ', integral:0:9, ', exected: ', integral_recipx2(a, b):0:9);
    2: WriteLn(' is ', integral:0:9, ', error: ', err:0:9, ', exected: ', integral_recipx2(a, b):0:9);
    3: WriteLn(' cannot be calculated: Error in input data');
    4: WriteLn(' cannot be calculated: Divergent, or calculation converges too slowly.');
  end;
end;

begin
  WriteLn('Integral of f(x) = 1/x^2');
  Execute(1.0, 2.0);
  Execute(1.0, 1.0);
  Execute(2.0, 1.0);
  Execute(1.0, Infinity);
  Execute(-Infinity, -1.0);
  Execute(0.0, Infinity);
  // NOTE: The next line will raise an exception if run in the IDE. This will not happen outside the IDE.
  // Integrate(-1.0, Infinity);
end.
Ordinary differential equations (unit ode)
Solving a single first-order differential equation
The routine odeiv1 solves an initial value problem described by a first-order differential equation of the form $\begin{cases} y' = f(x, y), \qquad x \in [a, b]\\ y(a) = \alpha \end{cases}$ with given a, b, f and initial condition y(a) = α.
procedure odeiv1(f: rfunc2r; a, ya: ArbFloat; var b, yb: ArbFloat; ae: ArbFloat; var term: ArbInt);fis the funtion to be processed. It depends on two real variables and returns a real value, as declared in unit typ astype rfunc2r = function(x, y: ArbFloat): ArbFloat.ais the x value of the starting point of the interval in which the solution is determined.yais the value α of the function at the starting point a (initial value).bis the x value of the end point of the interval in which the solution is determined. The casea > bis allowed. If, after the calculation, the error codetermis 2 then the interval has been changed, andbcontains the new endpoint to which the solution could be calculated with the desired accuracy,ae. In all other cases,bis unchanged.ybreturns the result of the calculation ifterm< 3. It is the value of the function at the end point b of the interval. Ifterm = 3then the result is undefined.aedefines the absolute accuracy with which the value y(b) must be determined.termreturns an error code:- 1 - successful completion
- 2 - the solution could not reach the point b with the required accuracy. However,
ybis a sufficiently accurate approximation of y at the deliveredb. - 3 - input error:
ae <= 0
The algorithm is adaptive and is based on an explicit one-step Runge-Kutta method of order five.
The procedure is not suitable for a rigid differential comparison.
The accuracy can not be guaranteed in all cases. In so-called unstable problems, e.g. small variations in y(a) give large variations in y(b), the error may be significantly larger than what the result of the procedure suggests. Call the procedure with different values of ae to investigate this case.
If one wants to solve the initial value problem for a number of points, e.g. from x = 0 to x = 1 with step size 0.1, then it is advisable to "integrate" and thus not to restart at x = 0 with every new step.
Example
Solve the differential equation y" = -10 (y - x<sup>2</sup>) with the initial condition y(0) = 0 for x = 0, 0.5, ..., 5. Compare with the exact solution y(x) = -0.02 exp(-10 x) + x<sup>2</sup> - 0.2 x + 0.02
program solve_ode;

uses
  typ, ode;

  function f(x, y: ArbFloat): Arbfloat;
  begin
    Result := -10 * (y - sqr(x));
  end;

  function exact(x: real): real; far;
  begin
    Result := -0.02*exp(-10*x) + sqr(x) - 0.2*x + 0.02;
  end;

const
  d = 0.5;         // interval length
  ae = 1e-5;
  n = 10;

var
  a, b: ArbFloat;
  ya, yb: ArbFloat;
  term: ArbInt;
  i: Arbint;

begin
  // Set initial conditions
  a := 0.0;
  b := a + d;
  ya := 0.0;

  WriteLn('x':12, 'y':12, 'exact':12, 'error code':17);
  WriteLn;
  WriteLn(a:12:5, ya:12:5, exact(a):12:5, '-':17);

  for i := 1 to n do begin
    odeiv1(@f, a, ya, b, yb, ae, term);
    WriteLn(b:12:5, yb:12:5, exact(b):12:5, term:17);
    a := b;
    ya := yb;
    b := b + d;
  end;
end.
Solving a system of first-order differential equations
An initial value problem described by system of first-order differential equations can be solved by the procedure odeiv2: $\begin{cases} \mathbf{y}' = \mathbf{f}(x, \mathbf{y}), \qquad x \in [a, b]\\ \mathbf{y}(a) = \mathbf{\alpha} \end{cases}$
where
- y is an unknown n vector
y: [a, b] --> R<sup>n</sup>
or: y = [y<sub>1</sub>(x), y<sub>2</sub>(x), ..., y<sub>n</sub>(x)]
- f is a vector function
f: [a, b] --> R<sup>n</sup>
or: f(x, y) = [f<sub>1</sub>(x,y), f<sub>2</sub>(x,y), ..., f<sub>n</sub>(x,y)]
- a, b, and the initial conditions α = y(a) = [y<sub>1</sub>(a), y<sub>2</sub>(a), ... y<sub>n</sub>(a)] are given.
The algorithm is based on an explicit one-step Runge-Kutta method of order five with variable step size.
procedure odeiv2(f: oderk1n; a: ArbFloat; var ya, b, yb: ArbFloat; n: ArbInt; ae: ArbFloat; var term: ArbInt);- The parameter
fcontains the name of the procedure that calculates the function values ***f<sub>i</sub>***(x, y<sub>i</sub>). The declaration of the procedure must match thetype oderk1n = procedure(x: ArbFloat; var y, fxy: ArbFloat)declared in unit typ. Herexis the coordinate in the interval [a, b], andyis the first value of an array of y values to be used in each equation of the ODE system. The function result is returned in another array which is specified by its first valuefxy. Both arrays must be dimensioned to provide at least n elements. ais the begin of the calculation interval.yais the first element of an array containing the initial conditions for each ODE of the system, i.e. the function values y<sub>i</sub>(a) = α<sub>i</sub>. The array must be allocated to containt at least n elements.bis the end of the calculation interval. The casea > bis allowed. If after the calculationtermis 2 then the interval has been changed, andbcontains the new endpoint to which the solution could have been calculated with the desired accuracy,ae. In all other cases,bis unchanged.ybis the first element of an array which receives the results of the calculation. It must be dimensioned to contain at least n elements.ndenotes the number of equations in the system.aespecifies the absolute accuracy with which the solution must be calculated.termis an error code:- 1 - successful completion.
- 2 - the solution could not reach the point b with the required accuracy. However, the values in the
ybarray are sufficiently accurate approximations of the y values at the deliveredb. - 3 - input error:
n < 1, orae <= 0.
Example
Integrate the following initial value problem between x = 0 and x = 1 with step size 0.1: $\begin{cases} y'_{1}=2xy_{1}+y_{2} \\ y'_{2}=-y_{1}+2xy_{2}\\ y_1(0)=0,\ y_2(0)=1 \end{cases}$
The exact solutions are $\begin{cases} y_1(x)=\exp({x^2}) \sin(x) \\ y_2(x)=\exp({x^2}) \cos(x) \end{cases}$
program solve_ode_sys;

uses
  typ, ode;

const
  ae = 1e-5;

  procedure f(x: ArbFloat; var y, fxy: ArbFloat);
  var
    _y: array[1..2] of ArbFloat absolute y;
    _fxy: array[1..2] of ArbFloat absolute fxy;
  begin
    _fxy[1] := 2*x*_y[1] + _y[2];
    _fxy[2] := -_y[1] + 2*x*_y[2]
  end;

  function exact1(x: ArbFloat): ArbFloat;
  begin
    Result := exp(x*x) * sin(x);
  end;

  function exact2(x: ArbFloat): ArbFloat;
  begin
    Result := exp(x*x) * cos(x);
  end;

var
  a, b, d: ArbFloat;
  ya: array[1..2] of ArbFloat;
  yb: array[1..2] of ArbFloat;
  term: ArbInt;
  i: Arbint;
  n: ArbInt;

begin
  // Set initial conditions
  a := 0.0;
  b := 0.1;
  d := b - a;
  ya[1] := 0.0;
  ya[2] := 1.0;
  n := 10;

  WriteLn('x':12, 'y[1]':12, 'y[2]':12, 'exact[1]':12, 'exact[2]':12, 'error code':17);
  WriteLn;
  WriteLn(a:12:5, ya[1]:12:5, ya[2]:12:5, exact1(a):12:5, exact2(a):12:5, '-':17);

  for i := 1 to n do begin
    odeiv2(@f, a, ya[1], b, yb[1], 2, ae, term);
    WriteLn(b:12:5, yb[1]:12:5, yb[2]:12:5, exact1(b):12:5, exact2(b):12:5, term:17);
    a := b;
    ya[1] := yb[1];
    ya[2] := yb[2];
    b := b + d;
  end;
end.
Interpolation and fitting (unit ipf)
Unit ipf contains routines for
- fitting a set of data points with a polynomial,
- interpolating or fitting a set of data points with a natural cubic spline. A spline is a piecewise defined function of polynomials which has a high degree of smoothness at the connection points of the polynomials ("knots"). In case of a natural cubic spline, the polynomials have degree 3 and their second derivative is zero at the first and last knot.
Fitting means: determine an approximating smooth function such that the deviations from the data points are at minimum.
Interpolation means: determine a function that runs exactly through the data points.
Use of polynomials or splines is recommended unless the data are known to belong to a known function in which there are still some unknown parameters, for example, the data are measurements of the function ''f(x) = a + b e<sup>-c x</sup>.
In the most common case, the data contain measurement errors and appear to follow the shape of a "simple" function. Therefore, it is recommended to first try to fit with a low-degree polynomial, e.g. not higher than degree 5. If this is not successful or if the shape of the function is more complicated try to fit with a spline.
If the data contain no (or very little) measurement noise, it is almost always wise to interpolate the data with a spline.
Fitting with a polynomial
For this purpose, the routine ipfpol can be applied. It uses given data points (x<sub>i</sub>, y<sub>i</sub>), i = 1, ..., m, and n given coefficients b<sub>0</sub>, ..., b<sub>n</sub> to calculate a polynomial $\operatorname{p}(x) = b_0 + b_1 x + \dots + b_n x^n$
In the sense of the least squares fitting, the coefficients b<sub>0</sub> ... b<sub>n</sub> are adjusted to minimize the expression
$\sum_{i=1}^m {(\operatorname{p}(x) - y_i)^2}$
procedure ipfpol(m, n: ArbInt; var x, y, b: ArbFloat; var term: ArbInt);mdenotes the number of data points. It is required thatm ≥ 1nis the degree of the polynomial to be fitted. It is required thatn > 0.xis the first element of a one-dimensional array containing the x values of the data points. The array must be allocated to contain at leastmvalues.yis the first element of a one-dimensional array containing the y values of the data points. The array must be dimensioned to contain at leastmvalues.bis the first element of a one-dimenisonal array in which the determined polynomial coefficients are returned iftermis 1. The array must have been dimensioned to provide space for at leastn + 1values. The returned coefficients are ordered from lowest to highest degree.termreturns an error code:- 1 - successful completion, the array
bcontains valid coefficients - 3 - input error:
n < 0, orm < 1.
- 1 - successful completion, the array
After the coefficients b<sub>0</sub>, ..., b<sub>n</sub> once have been determined the value of p(x) can be calculated for any x using the procedure spepol from the unit spe.
Note: With this routine, of course, an interpolating polynomial can also be determined by equaling n to m - 1.
Example
Fit a polynomial of degree 2 to these data points: $`\begin{array}{ccc} \hline i & x_i & y_i \ \hline
1 & 0.00 & 1.26 \\
2 & 0.08 & 1.37 \\
3 & 0.22 & 1.72 \\
4 & 0.33 & 2.08 \\
5 & 0.46 & 2.31 \\
6 & 0.52 & 2.64 \\
7 & 0.67 & 3.12 \\
8 & 0.81 & 3.48
\end{array}`$ 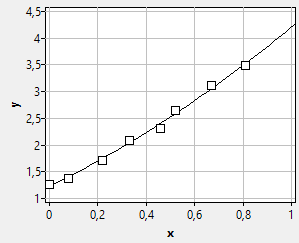
program polynomial_fit;

uses
  SysUtils, StrUtils, typ, ipf, spe;

const
  m = 8;
  n = 2;
  x: array[1..m] of Arbfloat = (
    0.00, 0.08, 0.22, 0.33, 0.46, 0.52, 0.67, 0.81
  );
  y: array[1..m] of Arbfloat = (
    1.26, 1.37, 1.72, 2.08, 2.31, 2.64, 3.12, 3.48
  );

var
  b: array[0..n] of ArbFloat;
  i: Integer;
  term: ArbInt;
  xint, yint: ArbFloat;
begin
  WriteLn('Fitting a polynomial of degree 2: p(x) = b[0] + b[1] x + b[2] x^2');
  WriteLn;

  WriteLn('Data points');
  WriteLn('i':10, 'xi':10, 'yi':10);
  for i:=1 to m do
    WriteLn(i:10, x[i]:10:2, y[i]:10:2);
  WriteLn;

  // Execute fit
  ipfpol(m, n, x[1], y[1], b[0], term);

  // Display fitted polynomial coefficients
  WriteLn('Fitted coefficients b = ');
  WriteLn(b[0]:10:6, b[1]:10:6, b[2]:10:6);
  WriteLn;

  // Interpolate and display fitted polynomial for some x values
  WriteLn('Some interpolated data');
  WriteLn('':10, 'x':10, 'y':10);
  for i:= 1 to 5 do begin
    xint := 0.2*i;
    yint := spepol(xint, b[0], n);
    WriteLn('':10, xint:10:2, yint:10:2);
  end;
end.
Interpolation with a natural cubic spline
The routine ipfisn can be used for this purpose. It calculates the parameters of the spline. Once these parameters are known, the value of the spline can be calculated at any point using the ipfspn procedure.
Assume that (x<sub>i</sub>, y<sub>i</sub>*),i= 0, ...,*n' are the given data points with x<sub>0</sub> < x<sub>1</sub> < ... < x<sub>n</sub>. Then assume a function g(x) which is twice continuously differentiable (i.e., the first and second derivatives exist and are continuous) and which interpolates the data (i.e., g(x<sub>i</sub> = y<sub>i</sub>). Imagine g(x) as the shape of a thin flexible bar. Then the bending energy (in first approximation) is proportional to
$\int_{-\infty}^{\infty} g''(x)^2 dx$
The interpolating natural spline s can be understood as the function g which minimizes this integral and therefore the bending energy.
The spline s has the following properties:
- s is a cubic polynomial on the interval [x<sub>i</sub>, x<sub>i+1</sub>]
- it is twice continuously differentiable on (-∞, ∞)
- s"(x<sub>0</sub>) = s"(x<sub>n</sub>) = 0
- on (-∞, x<sub>0</sub>) and (x<sub>n</sub>, ∞) s is linear.
procedure ipfisn(n: ArbInt; var x, y, d2s: ArbFloat; var term: ArbInt);- Calculates the second derivatives of the splines at the knots x<sub>i</sub>.
nis the index of the last data point, i.e. there aren+1data points.xis the first element of the array with the x coordinates of the data points. It must be dimensioned to contain at lastn+1values. The standard declaration would bevar x: array[0..n] of ArbFloat. The data points must be in strictly ascending order, i.e. there must not be any data points for which x<sub>i</sub> >= x<sub>i+1</sub>.yis the first element of the array with the y coordinates of the data points. It must be dimensioned to contain at lastn+1values. The standard declaration would bevar y: array[0..n] of ArbFloat.d2sis the first element of the array which receives the second derivatives of the splines at the knots if the returned error codetermis 1. Note that the array does not contain values for the first and last data point because they are automatically set to 0 (natural splines). Therefore the array must be dimensioned to contain at leastn-1elements. The standard declaration would be:var d2s: array[1..n-1] of ArbFloattermreturns an error code:- 1 - successful completion, the array beginning at
d2scontains valid data - 2 - calculation of the second derivatives was not successful
- 3 - incorrect input parameters: n ≤ 1, or x<sub>i</sub> ≥ x<sub>i+1</sub>
- 1 - successful completion, the array beginning at
function ipfspn(n: ArbInt; var x, y, d2s: ArbFloat; t: ArbFloat; var term: ArbInt): ArbFloat;- Calculates the value of the spline function at any coordinate t. The calculation uses the second derivatives determined by
ipnisn. n,x,y,d2shave the same meaning as abovetermreturns an error code:- 1 - successful completion
- 3 - The calculation could not be executed because n ≤ 1.
Example
Interpolate a natural cubic spline through the following data points: $`\begin{array}{ccc} \hline i & x_i & y_i \ \hline
0 & 0.00 & 0.980 \\
1 & 0.09 & 0.927 \\
2 & 0.22 & 0.732 \\
3 & 0.34 & 0.542 \\
4 & 0.47 & 0.385 \\
5 & 0.58 & 0.292 \\
6 & 0.65 & 0.248 \\
7 & 0.80 & 0.179 \\
8 & 0.93 & 0.139
\end{array}`$ 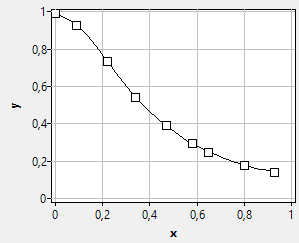
program spline_interpolation;

uses
  typ, ipf;

const
  n = 8;
  x: array[0..n] of Arbfloat = (
    0.00, 0.09, 0.22, 0.34, 0.47, 0.58, 0.65, 0.80, 0.93
  );
  y: array[0..n] of Arbfloat = (
    0.990, 0.927, 0.734, 0.542, 0.388, 0.292, 0.248, 0.179, 0.139
  );

var
  s: array[0..n] of ArbFloat;
  d2s: array[1..n-1] of ArbFloat;
  i: Integer;
  term: ArbInt;
  xint, yint: ArbFloat;
begin
  WriteLn('Interpolation with a natural cubic spline');
  WriteLn;

  WriteLn('Data points');
  WriteLn('i':10, 'xi':10, 'yi':10);
  for i:=0 to n do
    WriteLn(i:10, x[i]:10:2, y[i]:10:3);
  WriteLn;

  // Interpolation
  ipfisn(n, x[0], y[0], d2s[1], term);

  // Display 2nd derivatives of splines at xi
  WriteLn('s"(xi)');
  Write(0.0:10:6);      // 2nd derivative of 1st point is 0
  for i:=1 to n-1 do
    Write(d2s[i]:10:6);
  WriteLn(0.0:10:6);    // 2nd derivative of last point is 0
  WriteLn;

  // Interpolate for some x values
  WriteLn('Some interpolated data');
  WriteLn('':10, 'x':10, 'y':10);
  for i:= 1 to 5 do begin
    xint := 0.2 * i;
    yint := ipfspn(n, x[0], y[0], d2s[1], xint, term);
    WriteLn('':10, xint:10:2, yint:10:2);
  end;

end.
Fitting with a natural cubic spline
The routine ipffsn can be used for this purpose. This routine calculates the spline-fit parameters. Once these parameters are known the value of the spline can be calculated at any point using the procedure ipfspn.
Following the model with the bending energy in the previous chapter the calculated fit minimizes
$\int_{-\infty}^{\infty} g''(x)^2 dx + \lambda \sum_{i=0}^n (g(x_i) - y_i)^2$
where the parameter λ must be determined. It is a measure of the compromise between the "smoothness" of the fit - which is measured by the integral (the bending energy) - and the deviation of the fit to the given data - which is measured by the sum of squares. The solution is again a natural cubic spline.
Warning: The procedure
ipffsnis buggy and crashes. Therefore, it is not documented at the moment.
Special functions (unit spe)
Evaluation of a polynomial
Horner's scheme provides an efficient method for evaluating a polynomial at a specific x value:
$\operatorname{p}(x) = a_0 + a_1 x + a_2 x^2 + ... + a_n x^n \ \Rightarrow \ \operatorname{p}(x) = a_0 + x (a_1 + x (a_2 + \dots + x (a_{n-1} + x a_n)))$
This method is applied in NumLib's procedure spepol:
function spepol(x: ArbFloat; var a: ArbFloat; n: ArbInt): ArbFloat;xis the argument at which the polynomial is evaluated.ais the first element of an array containing the polynomial coefficients a<sub>0</sub>, a<sub>1</sub>, a<sub>2</sub>, ... a<sub>n</sub>. The coefficient must be ordered from lowest to highest degree.nis the degree of the polynomial, i.e. there aren+1elements in the array.
Example
Evaluate the polynomial
$\operatorname{p}(x) = 2 x^3 - 6 x^2 + 2 x - 1$
at x = 3. Note that the terms are not in the correct order for spepol and rearrange them to
$\operatorname{p}(x) = -1 + 2 x - 6 x^2 + 2 x^3$
program polynomial;

uses
  typ, spe;

const
  n = 3;
  a: array[0..n] of ArbFloat = (-1, 2, -6, 2);

var
  x, y: ArbFloat;
begin
  x := 3.0;
  y := spepol(x, a[0], n);
  WriteLn(y:0:6);
end.
Error function
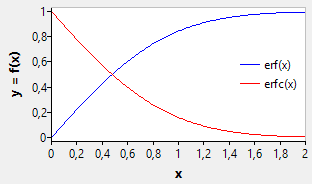 The error function erf(x) and its complement, the complementary error function erfc(x), are the lower and upper integrals of the Gaussian function, normalized to unity:
$\operatorname{erf}(x) = \frac {2} {\sqrt{\pi}} \int_0^x e^{-{t}^2} dt$
$\operatorname{erfc}(x) = \frac {2} {\sqrt{\pi}} \int_x^\infty e^{-{t}^2} dt = {1} - \operatorname{erf}(x)$
Both functions can be calculated by the NumLib functions speerf and speefc, respectively
function speerf(x: ArbFloat): ArbFloat;   // --> erf(x)
function speefc(x: ArbFloat): ArbFloat;   // --> erfc(x)
Example
A table of some values of the error function and the complementary error function is calculated in the following demo project:
program erf_Table;

uses
  SysUtils, StrUtils, typ, spe;

const
  Wx = 7;
  Wy = 20;
  D = 6;

var
  i: Integer;
  x: ArbFloat;
  fs: TFormatSettings;
begin
  fs := DefaultFormatSettings;
  fs.DecimalSeparator := '.';
  WriteLn('x':Wx, 'erf(x)':Wy+1, 'erfc(x)':Wy+1);
  WriteLn;
  for i:= 0 to 20 do begin
    x := 0.1*i;
    WriteLn(Format('%*.1f %*.*f %*.*f', [
      Wx, x,
      Wy, D, speerf(x),
      Wy, D, speefc(x)
    ], fs));
  end;
end.
Normal distribution
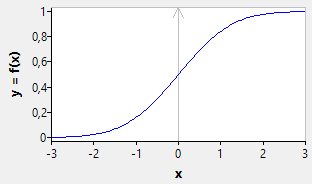 The (cumulative) normal distribution is the integral of the Gaussian function with zero mean and unit standard deviation, i.e.
$\operatorname{N}(x) = \frac{1}{\sqrt{2\pi}} \int_{-\infty}^{x} \operatorname{exp}(\frac{t^2}{2}) dt = \frac{1}{2}[1 + \operatorname{erf} (\frac{x}{\sqrt{2}})]$
Suppose a set of random floating point numbers which are distributed according to this formula. Then N(x) measures the probability that a number from this set is smaller than x.
In NumLib, the normal distribution is calculated by the function normaldist:
function normaldist(x: ArbFloat): ArbFloat;xcan take any value between -∞ and +∞.- The function result is between 0 and 1.
The inverse normal distribution of y returns the x value for which the normal distribution N(x) has the value y.
function invnormaldist(y: ArbFloat): ArbFloat;yis allowed only between 0 and 1.- The function can take any value between -∞ and +∞.
Note: The functions
normaldistandinvnormaldistare not available in fpc 3.0.x and older.
Example
Calculate the probabilities for x = -10, -8, ..., 12 for a normal distribution with mean μ = 2 and standard deviation σ = 5. In order to reduce this distribution to the standard normal distribution implemented by NumLib, we introduce a transformation x<sub>r</sub> = (x - μ)/σ.
program normdist;

uses
  typ, spe;

const
  mu = 2.0;
  sigma = 5.0;
  x: array[0..12] of ArbFloat = (-10, -8, -6, -4, -2, 0, 2, 4, 6, 8, 10, 12, 14);

var
  xr, y: ArbFloat;
  i: Integer;
begin
  WriteLn('Normal distribution with mean ', mu:0:1, ' and standard deviation ', sigma:0:1);
  WriteLn;
  WriteLn('x':20, 'y':20);

  for i:= 0 to High(x) do begin
    xr := (x[i] - mu) / sigma;
    y := normaldist(xr);
    WriteLn(x[i]:20:1, y:20:6);
  end;
end.
Gamma function
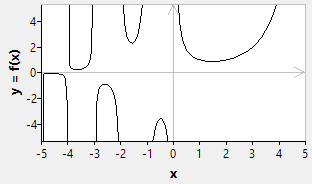 The gamma function is needed by many probability functions. It is defined by the integral
$\Gamma({x}) = \int_0^{\infty}t^{x-1} e^{-t} dt$
NumLib provides two functions for its calculation:
function spegam(x: ArbFloat): ArbFloat;
function spelga(x: ArbFloat): ArbFloat;
The first one, spegam, calculates the function directly. But since the gamma function grows rapidly for even not-too large arguments this calculation very easily overflows.
The second function, spelga calculates the natural logarithm of the gamma function which is more suitable to combinatorial calculations where multiplying and dividing the large gamma values can be avoided by adding or subtracting their logarithms.
Example
The following demo project prints a table of some values of the gamma function and of its logarithm. Note that spegam(x) overflows above about x = 170 for data type extended.
program Gamma_Table;

uses
  SysUtils, StrUtils, typ, spe;

const
  VALUES: array[0..2] of ArbFloat = (1, 2, 5);
  Wx = 7;
  Wy = 30;
  Wln = 20;

var
  i: Integer;
  x: ArbFloat;
  magnitude: ArbFloat;
begin
  WriteLn('x':Wx, 'Gamma(x)':Wy, 'ln(Gamma(x))':Wln);
  WriteLn;
  magnitude := 1E-3;
  while magnitude <= 1000 do begin
    for i := 0 to High(VALUES) do begin
      x := VALUES[i] * magnitude;
      Write(PadLeft(FloatToStr(x), Wx));
      if x <= 170 then  // Extended overflow above 170
        Write(FormatFloat('0.000', spegam(x)):Wy)
      else
        Write('overflow':Wy);
      WriteLn(spelga(x):Wln:3);
      if abs(x-1000) < 1E-6 then
        break;
    end;
    magnitude := magnitude * 10;
  end;
end.
Incomplete gamma function
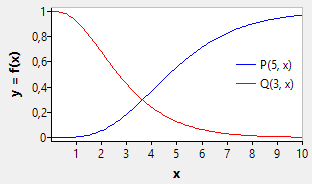 The lower and upper incomplete gamma functions are defined by
$\operatorname{P}({s},{x}) = \frac{1}{\Gamma({s})} \int_0^{x}t^{s-1} e^{-t} dt$
$\operatorname{Q}({s},{x}) = \frac{1}{\Gamma({s})} \int_{x}^{\infty}t^{s-1} e^{-t} dt = 1 - \operatorname{P}({s}, {x})$
function gammap(s, x: ArbFloat): ArbFloat;
function gammaq(s, x: ArbFloat): ArbFloat;- The parameter
smust be positive: s > 0 - The argument
xmust not be negative: x ≥ 0 - The function results are in the interval [0, 1].
Note: The functions
gammapandgammaqare not available in fpc v3.0.x and older.
Example
The following project prints out a table of gammap and gammaq values:
program IncompleteGamma_Table;

uses
  SysUtils, StrUtils, typ, spe;

const
  s = 1.25;

  Wx = 7;
  Wy = 20;
  D = 6;

var
  i: Integer;
  x: ArbFloat;
  fs: TFormatSettings;
begin
  fs := DefaultFormatSettings;
  fs.DecimalSeparator := '.';
  WriteLn('x':Wx, 'GammaP('+FloatToStr(s,fs)+', x)':Wy+1, 'GammaQ('+FloatToStr(s,fs)+', x)':Wy+1);
  WriteLn;
  for i := 0 to 20 do begin
    x := 0.5*i;
    WriteLn(Format('%*.1f %*.*f %*.*f', [
      Wx, x,
      Wy, D, gammap(s, x),
      Wy, D, gammaq(s, x)
    ], fs));
  end;
end.
Beta function
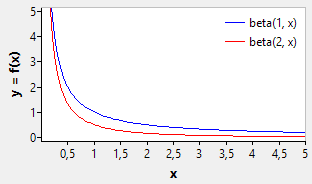 The Beta function is another basis of important functions used in statistics. It is defined as
$\operatorname{B}(a, b) = \frac{\Gamma(a+b)} = \int_0^1{t^{x-1} (1-t)^{y-1} dt}$
The NumLib routine for its calculation is
function beta(a, b: ArbFloat): ArbFloat;- The arguments
aandbmust be positive:a> 0andb> 1. - The calculation is based on the logarithms of the gamma function and therefore does not suffer from the overflow issues of the gamma function.
Note: The function
betais not available in fpc v3.0.x or older.
Incomplete beta function
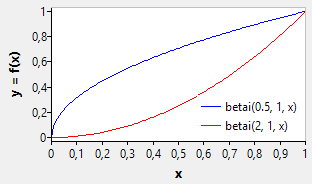 The (regularized) incomplete beta function is defined by
$\operatorname{I}_x(a,b) = \frac {1}{\operatorname{B}(ab)} \int_0^x{t^{x-1} (1-t)^{y-1} dt}$
function betai(a, b, x: ArbFloat): ArbFloat;- The arguments
aandbmust be positive:a> 0andb> 1. xis only allowed to be in the range 0 ≤ x ≤ 1.- The function result is in the interval [0, 1].
The inverse incomplete beta function determines the argument x for which the passed parameter is equal to I<sub>x</sub>(a, b):
function invbetai(a, b, y: ArbFloat): ArbFloat;- The arguments
aandbmust be positive:a> 0andb> 1. yis only allowed to be in the range 0 ≤ x ≤ 1.- The function result is in the interval [0, 1].
Note: The functions
betaiandinvbetaiare not available in fpc v3.0.x and older.
Example
Calculate the incomplete beta function for some values of x, a, b, and apply the result to the inverse incomplete beta function to demonstrate the validity of the calculations.
program incomplete_beta_func;

uses
  SysUtils, typ, spe;

  procedure TestBetai(a, b, x: ArbFloat);
  var
    xc, y: ArbFloat;
  begin
    y := betai(a, b, x);
    xc := invbetai(a, b, y, macheps);
    WriteLn('  x = ', x:0:6, '  --->  y = ', y:0:9, '  --->  x = ', xc:0:6);
  end;

begin
  WriteLn('Incomplete beta function and its inverse');
  WriteLn;
  WriteLn('        y = betai(1, 3, x)      x = invbetai(1, 3, y)');
  TestBetaI(1, 3, 0.001);
  TestBetaI(1, 3, 0.01);
  TestBetaI(1, 3, 0.1);
  TestBetaI(1, 3, 0.2);
  TestBetaI(1, 3, 0.9);
  TestBetaI(1, 3, 0.99);
  TestBetaI(1, 3, 0.999);
  WriteLn;

  WriteLn('        y = betai(1, 1, x)      x = invbetai(1, 1, y)');
  TestBetaI(1, 1, 0.001);
  TestBetaI(1, 1, 0.01);
  TestBetaI(1, 1, 0.1);
  TestBetaI(1, 1, 0.2);
  TestBetaI(1, 1, 0.9);
  TestBetaI(1, 1, 0.99);
  TestBetaI(1, 1, 0.999);
  WriteLn;

  WriteLn('        y = betai(3, 1, x)      x = invbetai(3, 1, y)');
  TestBetaI(3, 1, 0.001);
  TestBetaI(3, 1, 0.01);
  TestBetaI(3, 1, 0.1);
  TestBetaI(3, 1, 0.2);
  TestBetaI(3, 1, 0.9);
  TestBetaI(3, 1, 0.99);
  TestBetaI(3, 1, 0.999);
  WriteLn;
end.
Bessel functions
The Bessel functions are solutions of the Bessel differential equation:
${x}^2 y'' + x y' + ({x}^2 - \alpha^2) {y} = 0$
The Bessel functions of the first kind, or cylindrical harmonics, J<sub>α</sub>(x), are the solutions which are not singular at the origin, in contrast to the Bessel functions of the second kind, Y<sub>α</sub>(x). Y<sub>α</sub>(x) is only defined for x > 0.
Example
- Calculate the probability that random normal-distributed numbers are within 1, 2, and 3 standard deviations around the mean.
- Calculate the maximum deviation of normal-distributed deviates (in units of standard deviations) from the mean at probabilities 0.90, 0.95, 0.98, 0.99 and 0.999.
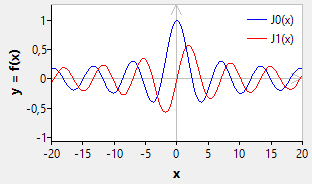
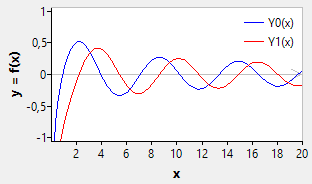
The solutions for a purely imaginary argument are called modified Bessel functions of the first kind, I<sub>α</sub>(x), and modified Bessel function of the second kind, K<sub>α</sub>(x). K<sub>α</sub>(x) is only defined for x > 0.
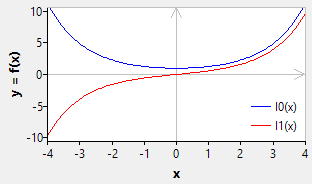
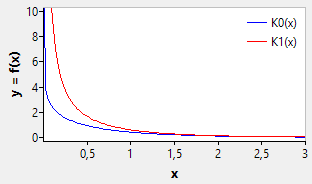
NumLib implements only the solutions for the parameters α = 0 and α = 1:
function spebj0(x: ArbFloat): ArbFloat;     // Bessel function of the first kind, J0 (alpha = 0)
function spebj1(x: ArbFloat): ArbFloat;     // Bessel function of the first kind, J1 (alpha = 1)

function speby0(x: ArbFloat): ArbFloat;     // Bessel function of the second kind, Y0 (alpha = 0)
function speby1(x: ArbFloat): ArbFloat;     // Bessel function of the second kind, Y1 (alpha = 1)

function spebi0(x: ArbFloat): ArbFloat;     // modified Bessel function of the first kind, I0 (alpha = 0)
function spebi1(x: ArbFloat): ArbFloat;     // modified Bessel function of the first kind, I1 (alpha = 1)

function spebk0(x: ArbFloat): ArbFloat;     // modified Bessel function of the second kind, K0 (alpha = 0)
function spebk1(x: ArbFloat): ArbFloat;     // modified Bessel function of the second kind, K1 (alpha = 1)
Other functions
The unit spe contains some other functions which will not be documented here because they are already available in th FPC's standard unit math.
<thead>
in <em>math</em></th>
</thead> <tbody>
</tbody>
From the Free Pascal wiki, page "NumLib Documentation", as it stood on 2024-02-14 after a change by Wp, out of the wiki's dump of 2024-05-26. Copyright stays with the author who wrote it, according to the old wiki's Licensing page. If you have concerns about this material, message the admin.
Talk about this page
Nobody has opened a bench for this page yet. Sign in to open one.